Pankhuri Kishore1*, Stuti Shukla Datta2 , Seethalekshmi K. 3 and Anil Kumar2
1 Department of Electronics and Communication Engineering, Amity School of Engineering and Technology, Amity University Uttar Pradesh Lucknow Campus, India Department of Electrical and Electronics Engineering, Amity School of Engineering and Technology, Amity University Uttar Pradesh Lucknow Campus 226010, India 3 Department of Electrical Engineering, Institute of Engineering and Technology, Lucknow
226021, India *pankhuri.mmmec@gmail.com, Ssdatta@lko.amity.edu, seethalekshmik@ietlucknow.ac.in
Abstract: The integration of information and communication technology, and cyber components, electricity infrastructures have made power systems more open and accessible from outside networks. Thus, the system becomes more vulnerable to data manipulations. This paper aims at analyzing the impact of data manipulation, on power system state estimation under various system operating conditions and explores various options to recommend a robust solution approach under such uncertainties. In-state estimation, the measurements can be manipulated either by creating a contingency to the system or by interfering with injections or flows. Contribution of this work lies in analysing simulated impact, statistically through the computation of errors namely, mean error, standard error, standard deviation, and variance indices and also by a parametric test Further, the performance and robustness of the conventional and evolutionary methods, employed for state estimation, are analysed under different measurement uncertainties. Results of these estimators are compared with base values of state variables obtained through load flow solution and then the percentage error in the estimated values for each case study is calculated. The efficiency and robustness of the Weighted Least Square method, Genetic Algorithm, Particle Swarm Optimization, and Simulated Annealing techniques are evaluated on IEEE 6, 14, and 30 bus systems. Finally, a comparative analysis of the statistical results is conducted, proving that the GA-based state estimation is more efficient and robust than other conventional and evolutionary techniques.
Keywords: Contingency, Genetic algorithm, Infringed data, Particle swarm optimization, State estimation, Simulated Annealing, Weighted least square
1. Introduction
Electric utilities have long relied on supervisory control and data acquisition systems to help them monitor, operate, and control their power grids. Optimal operation of the system while ensuring security is the primary objective of the operation of the power system. For the same reason, it is imperative to accurately monitor and estimate the operating states of the power system. With the integration of information and communication technology (ICT) and cyber components, electricity infrastructures are gradually being transformed into smart grids, making power systems more open and accessible from outside networks, with two-way communication between supplier and customer. A weak communication network is highly vulnerable to unwanted intrusions. These intrusions will eventually lead to financial loss to the exchequer and to the general consumer who will be forced to pay a biased price for the electricity supply. It can also cause major technical problems such as blackouts in power systems causing financial and operational loss to industries using heavy machinery. Integration of energy management with cyber technologies has made the system more vulnerable to external interference for unethical financial advantage if proper preventive and detection measures are not available. The Energy Management System (EMS) is a vital part of an
Received: August 9th, 2021. Accepted: September 29th, 2021
DOI: 10.15676/ijeei.2021.13.3.11
electric grid that performs the calculations required for power system network monitoring, operation, and control. If the attackers gain access to the EMS, the decisions made based on the outputs provided by the EMS may be incorrect, resulting in disastrous results. The data in the EMS for power system state estimation can be manipulated either by creating the contingency in the system or by infringement in the measurement data. The estimated states can also be modified by changing the upper and the lower bounds of the voltage magnitudes and angles of the optimal solution. All the three scenarios can be broadly classified as false data injection attacks. Because false data injection attacks alter measured values artificially, the resulting values may not have the expected error distribution. Therefore, an optimally performing and robust state estimation algorithm is the prime interest of the system operator. Many papers in the literature have discussed the various techniques employed for solving the state estimation problem and the impact of false data injection attacks on power system state estimation, and methodologies for detecting such an attack but, it is found that many times the conventional state estimation techniques got trapped in the local optima whereas the evolutionary algorithms present a global optimal solution for an optimization problem. Therefore a comparative study is very much required to validate the same. State estimation, a vital tool for system monitoring [1], is carried out in energy control centres to obtain the best estimates of the state of the system based on real-time measurements and a predetermined system model. Several algorithms for solving state estimation problems are reported in the literature. State estimation, using iterative methods such as the Weighted Least Square technique and Gauss-Newton iterations [2, 3] are among the most widely used techniques. These methods worked well for the state estimator application, however, have problems with convergence if the initial guess is too far from the current operating state of the system. The problem of state estimation can also be solved non-iteratively through an adequate set of measurements, [4-6] however, it necessitates more real-time measurements and mathematical computations compared to iterative methods. An analysis of the condition number of the Hessian matrix is carried out for solving the estimation problem [7]. It discussed the process of selecting the types of measurements for state estimation. However, the challenge lies in addressing the border real and reactive power injections as State Estimation (SE) of each area is computed, separately. To overcome this challenge a method is proposed for an interconnected power system that uses a linear state estimation model with Phasor Measurement Unit (PMU) measurements, for PMU observable areas and a nonlinear state estimation models with Remote Terminal Unit (RTU) measurements for the remaining areas [8]. The problem of state estimation in a distribution network environment is formulated as an agent-based problem by the authors [9]. A decentralized procedure is used to find the solution of the state estimation problem in a multiarea network [10]. This method estimates the state of a multi-area electric energy system, while preserving, each area's independence. The drawback with the technique is that convergence is only guaranteed if the coupling between the areas is weak. Another significant drawback of this method is that the Hessian matrix cannot be computed in a decentralized manner because the normalized residual calculation is unclear.
Of late, Artificial Intelligence (AI) algorithms are being applied for solving nonlinear and complex optimization problems [11, 12]. The main advantage of these algorithms is that, unlike traditional algorithms that require gradient (derivative) information, these algorithms only require the fitness function to guide the search. A modified version of the Genetic Algorithm was introduced for the solution of state estimation [13]. The paper discusses the sensitivity of the proposed modified genetic algorithm to genetic operators. The algorithm was tested on IEEE 6 and 14 bus systems and compared for its performance with traditional weighted least square's formulation. The results show that modified GA works better for smaller power systems; however, the performance of the traditional method was better for large systems. Artificial Neural Network (ANN) has been utilized for state estimation [14]. The main advantage of ANN-based state estimators is that they produce more accurate results with a larger number of measurements than a weighted least square estimator. However, it also suffers from the drawback that there is no specific rule for determining the structure of artificial neural
networks. An appropriate network structure is achieved only through experience and trial and error.
The use of hybrid data to study neural network-based dynamic state estimation has also been extensively studied. Neural network-based estimations are also being investigated for micro grids. In the case of a clustered multi-area distribution network system, extensive research is also carried out. A survey of various state estimation approaches has also been conducted, along with their prospects and drawbacks. The literature also discusses the use of scalable deep learning and machine learning models for accurate forecasting of operating states in both healthy and contingency scenarios, as well as the comparative analysis of neural network models under various noise scenarios [15-19].
Many pieces of research were also conducted which use the technique of Particle Swarm Optimization (PSO) for state estimation. An Improved Particle Swarm Optimization (IPSO) and Gravitational Search Algorithm (GSA) were presented for state estimation [20]. A method of hybrid PSO is used by Naka for distribution system state estimation [21]. A comparison of different methods of state estimation has been done by Holten et al [22] while a comparative study of various models of PSO algorithm for power system state estimation has also been reported in literature [23]. An improved PSO algorithm is also used for optimization of transmission system security margin under (N-1) contingency in [33].
Two novel algorithms, the constrained extended Kalman filter (CEKF) and recursive constrained convex optimization, were used to estimate power system voltage/current signal parameters (amplitude, frequency, and phase) in the presence of random noise and distortions [24]. A detailed three-phase distribution network model has been developed and the use of state-of-the-art convex optimization techniques for estimating distribution system state is investigated and a comparison of the accuracy and convergence of these methods on a distribution system state estimator is also presented [25]. In [34], a novel optimization method for state estimation in three-phase unbalanced DG-integrated distribution systems, called hybrid PSOS-CGSA, is presented. Authors have investigated the benefits and drawbacks of the Non-Linear Weighted Least Square (NLWLS), Extended Kalman Filter (EKF), and Square-Root Unscented Kalman Filter (SRUKF) algorithms when used to estimate the state of a power system under various static and dynamic scenarios [26]. The authors conducted a bibliographic survey on static state estimation in power system [27]. The process of estimating the static state of a power system using various methodologies and developments in the literature has been discussed. The fundamental concepts and mathematical modelling, as well as methods for detecting, identifying, and eliminating bad data, are all covered. A technique of statistical analysis of variance has been used by the author for the measurement of two data sets using different techniques and different locations over 12 months period and checked whether the hypothesis of not having a significant difference between the two data sets holds valid or not [28].
The key objective of this paper is to address the impact of missing and infringed data in state estimation while considering the variation in the bounds of the state variables (the voltage magnitudes and angles), through conventional and evolutionary techniques. Though a number of evolutionary techniques are applied in this field, a statistical assessment of the methods is found to be missing in the literature, to authors' knowledge. Hence, the major contributions of this paper are:
- The concept of change in the upper and the lower bounds of the voltage magnitudes and angles have been incorporated and are assessed to have a significant impact on the prediction of states.
- The impact of missing and infringed measurement data on the state estimation solutions are brought out in the study.
- A statistical assessment along with the parametric test with 95% confidence level has been carried out for various conventional and heuristic techniques, including Genetic Algorithm (GA), Particle Swarm Optimization (PSO), and Simulated Annealing (SA) for the state estimation.
• Comparative performance analysis of the state estimation solutions through the conventional and evolutionary techniques has been carried out by comparing the results with the base values (voltage magnitudes and angles) obtained from the load flow analysis using the NR method. The efficacy of the various techniques is assessed on IEEE 6, 14, and 30 bus systems.
The organization of this paper is as follows. In Section I, a brief introduction to the topic is addressed, followed by a discussion of the formulation of the state estimation problem in Section II. It also covers the weighted least square method, genetic algorithm optimization, particle swarm optimization, and the simulated annealing algorithm for solving the power system state estimation problem along with the parametric t-test which is used to statistically assess the robustness of the algorithms. In Section III, detailed simulation studies along with the state estimation results and statistical analysis results for the three cases on IEEE 6, 14, and 30 bus systems are presented. In Section IV, complete result analysis has been presented, and in Section V, conclusive remarks are drawn.
2. State Estimation Problem Formulation
The state estimation involves evaluation of true value of state variables of the system by minimizing or maximizing the selected criterion. The problem can be addressed through deterministic iterative or through bounded algorithms like GA and PSO. It is clear from the mathematical equation given below that the measurements are related with the estimated values and the errors
\[z = h(x) + e \tag{1}\]
where:
z is the measurement vector of the order \((m \times 1)\);
x is a state vector that is to be estimated of the order \((n\times 1)\);
h is a vector of nonlinear functions that relates the states to the measurements;
e is a measurement error vector of the order (m×1).
m represents the number of measurements;
n represents the number of state variables.
A. Weighted Least Squares Method (WLS) State Estimator
The weighted least square method is the most common and well-known criterion for state estimation, to reduce the sum of squares of variations between each measured value and the true estimated value, with each square distinction divided or weighted by meter error variance. Mathematically the problem is stated as:
\[J(x) = \sum_{i=1}^{m} \left[ \frac{z_i - f_i(V_1, \dots, V_n, \delta_1, \dots, \delta_{n-1})}{\sigma_i^2} \right]^2\] (2)
Where
\(f_i\) is a function that is used to calculate the value which is being measured by the i<sup>th</sup> measurement
\(\sigma_i^2\) represents variance for the i<sup>th</sup> measurement
J(x) is measurement residual
m represents the number of independent measurements
n represents the number of buses, which means that we have 2n-1 unknown parameters.
\(z_i\) represents i<sup>th</sup> measurement
Main objective function is to minimize the Jacobian i.e.
\[F(x) = \min J(x) \tag{3}\]
The WLS state estimator leads to the iterative solution of the supposed normal equation
\[x_{est} = [[H]^T [R^{-1}][H]]^{-1} [H]^T [R^{-1}] z^{meas}\] (4)
Where \(R^{-l}\) represents the weighting matrix \((diag^{-l}(\sigma^2))\) H represents the Jacobian of f(x) represents the gain matrix G \(z^{meas}\) vector containing the measured values
B. Evolutionary Techniques
B.1. Power System State Estimation Using Genetic Algorithm
Genetic Algorithm (GA) is a heuristic search based optimization technique and is based on the Darwin's theory of evolution by natural selection. Each individual solution is associated with a fitness value which can be computed from a fitness function. This fitness value reflects, up to what extent a solution is good. These algorithms are much more powerful and efficient than random search and exhaustive search algorithms, and they do not require any extra information about the given problem. This feature of the algorithm allows them to find solutions to problems that other optimization methods cannot computes. The flowchart for state estimation using GA is shown in Figure 1.
For the state estimation problem, the fitness function is:
\[F(x) = \min J(x) \tag{5}\]
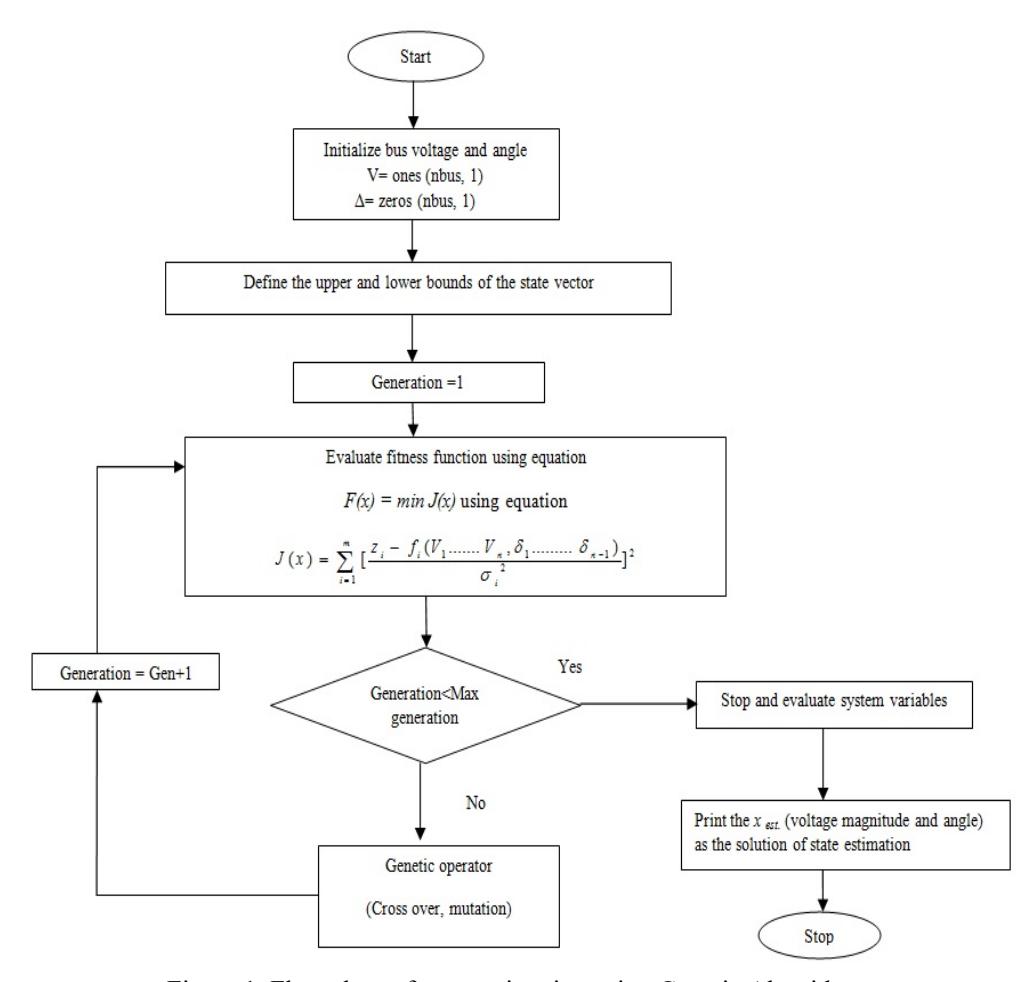
Figure 1. Flow chart of state estimation using Genetic Algorithm
B.2. Power System State Estimation Using Particle Swarm Optimization
Particle Swarm Optimization (PSO) was introduced by Kennedy and Eberhart in 1995 as another heuristic technique [29]. The summaries of recent advances in PSO are discussed by Xiaohui, Yuhui, and Eberhart in year 2004 [30]. Various versions of PSO were presented, but the most common is Shi and Eberhart global version of PSO (Gbest model), in which the entire populations treated as a single neighborhood throughout the optimization process [31]. Authors have presented various applications of PSO in an electrical power system [32].
The main characteristics of PSO are its simplicity and robustness, as it only uses two model equations to solve any problem. Each particle's coordinates represent a feasible solution associated with two vectors, the position \((x_i)\) and velocity \((v_i)\) vectors. In N- dimensional search
space \(X_i = [x_{i1}, x_{i2}, \dots, x_{iN}]\) and \(V_i = [v_{i1}, v_{i2}, \dots, v_{iN}]\) are the two vectors that are associated with each particle. A swarm is made up of a group of particles (or possible solutions) that move (fly) through the feasible solution space in search of the best solution. According to the following model, each particle updates its position based on its own best exploration; best swarm overall experience, and previous velocity vector
\[v_i^{k+1} = wv_i^k + c_1 r_1(pbest_i^k - x_i^k) + c_2 r_2(gbest^k - x_i^k)\] (6)
\[x_i^{k+1} = x_i^k + v_i^{k+1} (7)\]
where
\(c_1\) and \(c_2\) are two positive constants;
\(r_1\) and \(r_2\) are two randomly generated numbers with a range of [0,1];
w is the inertia weight;
\(pbest_i^k\) is the best position achieved by the particle based on its own experience
\[pbest_{i}^{k} = [x_{i1}^{pbest}, x_{i2}^{pbest}, ....x, pbest_{in}];\]
ghest<sup>k</sup> is the best particle position based on overall swarm's experience;
\[gbest^k = [x_1^{gbest}, x_2^{gbest}, ....., x_N^{gbest}];\]
k is the iteration index.
B.3. Algorithm for State estimation using PSO:
Step 1: Input, the bus data, line data and the measurement data.
Step 2: Initialize the population randomly; every particle of the population represents a potential solution of the give problem. For state estimation, the initial population is:
V= ones(nbus,1) and \(\Delta\)= zeros(nbus,1), where n is the no of buses.
Step 3: Using the results of the initial load flow solution, define the upper and the lower bounds of the state variables.
Step 4: Determine the local (personal) best (pbest) and global best (gbest) by evaluating the fitness function of every particle.
For the state estimation problem, the fitness function is:
\[F(x) = \min J(x) \tag{8}\]
Step 5: Exchange, the global best (gbest) value between the neighbours.
Step 6: Using eq. (6) and eq. (7), update the particle's velocity and position based on the pbest and the gbest values.
Step 7: The process will continue until the termination criterion is met.
Step 8: Stop the process and report the fittest particle which represents the most appropriate solution for the given problem
B.3. Power System State Estimation using Simulated Annealing
The third and the last technique opted for state estimation is Simulated Annealing (SA) which draws its motivation from metallurgy. The process of gradually cooling of the particles is numerically reproduced in this technique. Figure 2 represents the flow chart of the state estimation using Simulated Annealing.
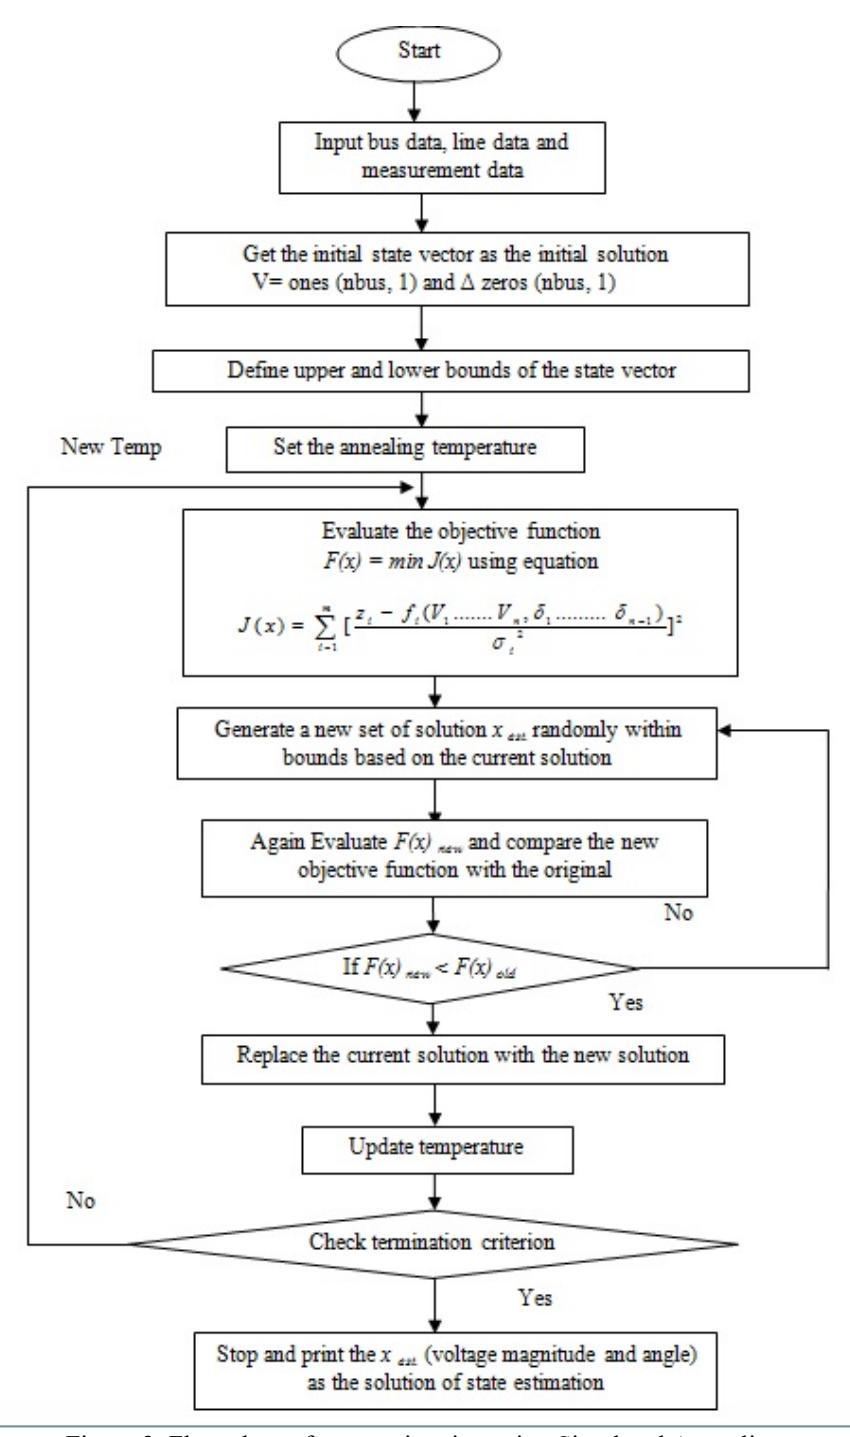
Figure 2. Flow chart of state estimation using Simulated Annealing
C. Statistical Assessment of Estimation Results using t-Test
A parametric test invented in 1908 by William Sealy Gusset, t-test, also known as the student's t-test. Statistical presumptions are of two types: (i) parametric (ii) Non-parametric. Parametric methods are statistical techniques for defining the probability distribution of probability variables and drawing conclusions about the distribution's parameters. Nonparametric methods are used in situations where the probability distribution cannot be defined. The t-Test is a parametric method for comparing the two means that work on normally distributed scale data. This statistical test is used to determine whether or not the two independent sample means differ significantly [28].
Steps for two sample t-test with equal variance
Step 1: Determine the null and alternate hypothesis.
Step 2: Compute the level of significance
Step 3: Find critical values.
Step 4: Compute the test statistics
\[t = \frac{\overline{x_A} - \overline{x_B}}{S_d \sqrt{\frac{1}{n_A} + \frac{1}{n_B}}} \tag{9}\]
\[DF = n_A + n_B - 2 \tag{10}\]
\[S_d = \sqrt{\frac{(n_A - 1)S_A^2 + n_B - 1)S_B^2}{n_A + n_B - 2}}\] (10)
where \(S_d\) is the pooled standard deviation
Step 5: Interpret the decision whether the hypothesis of having any significant difference with base values holds valid or not.
Steps for two sample t-test with unequal variance
Step 1: Determine the mean values of each sample.
Step 2: Calculate the variance of each sample.
Step 3: Compute t values.
Step 4: Calculate the degree of freedom.
Step 5: Compare the t calculated with the critical value in the t distribution table.
Step 6: Give the interpretation
Step 7: If the t calculated > t critical there is a significant difference between the two means and the hypothesis is rejected.
Step 8: If the t calculated < t critical there is no significant difference between the two means and the null hypothesis is accepted.
3. Simulation Studies
In this work, three case studies are carried out on the standard IEEE 6, 14, and 30 bus systems for state estimation. Since Genetic Algorithm (GA), Particle Swarm Optimization (PSO), and Simulated Annealing (SA) are evolutionary algorithms, it becomes imperative to evaluate their performances when the upper and the lower bounds of the voltage magnitudes and angles have been changed. Moreover, since the estimated states are based on the measured values, a huge probability of data being missed or not taken into consideration during state estimation exists. In addition, the unbundling of the system components has made the system vulnerable to false data injection. The measurement can be infringed by the market players for getting financial benefits. Considering the probable misbehaviour by the participants a scenario is studied where state estimation is carried out under the condition of infringement of the data.
Thus, following three case studies are presented in the paper for IEEE 6, 14 and 30 bus systems [351:
- 1. Variation in the bounds
- 2. Missing Data
- 3. Infringed Data
Furthermore, for each of the three scenarios, a statistical evaluation for various conventional and heuristic techniques, such as Genetic Algorithm (GA), Particle Swarm Optimization (PSO), and Simulated Annealing (SA), has been performed.
In statistical assessment, the percentage error in the estimated values is evaluated by comparing the algorithm's output values with the base values obtained from the load flow analysis using the Newton Raphson (NR) method of the respective bus systems. The statistical analysis of the percentage error has been carried out for each of three scenarios considered above and all the three scenarios are tested on IEEE 6, 14, and 30 bus systems. The following statistical metrics are considered for the evaluation purpose:
- 1) Mean- Mean helps to identify the central tendency of the data.
- 2) Standard deviation- This helps to identify the spread of the values from the central tendency
- 3) Standard Error When a group of data points is separated from the huge data or population; it is referred to as a sample. The deviation of sample mean from the population mean is called the standard error. The smaller the standard error, the more representative the estimated values will be of base values.
- 4) Variance- It refers to the square of standard deviation. It treats all the deviations from the mean in the same manner irrespective of the direction.
In this work, the robustness of the state estimation algorithms is also assessed with two sample t-test. The test is performed with 95% confidence level on the IEEE 14 and 30 bus systems under the conditions of missing and infringed data. The difference between the two independent population means is assessed using the two-sample t-test. t-Test gives us whether the hypothesis of having any significant difference with the base values holds valid or not. A t-test looks at the t-statistic, t-distribution values, and degrees of freedom to determine the probability of difference between two sets of data. If the probability comes out to be greater than .05, then it indicates that there is no significant difference between the two sets of data [28]. A parametric two-sample t-test is used in this paper to compare base values to estimated values by WLS, GA, PSO, and SA.
A. Case 1- Variation in the bounds
In this case, the state estimation is performed using WLS, GA, PSO, and SA considering a variation of,2% and 5% in the upper and the lower bounds, of state variables, i.e. voltage magnitudes and angles, obtained as the probable optimal solution.
IEEE 6 Bus System
a. State Estimation with Results
Figure 3(a) and 3(b) depict the comparative results of base values computed from Newton Raphson load flow analysis, WLS, GA, PSO, and SA state estimators to estimate the states of the standard IEEE 6 bus test system with 2% variation in bounds and Figure 4 (a) and 4(b) depicts the 5% variation in the bounds of voltage magnitudes and angles, respectively.
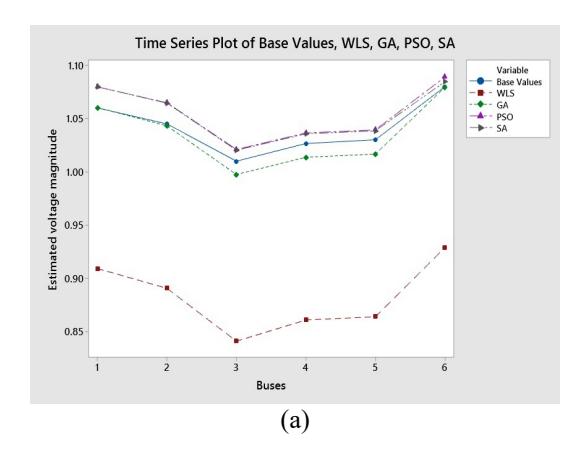
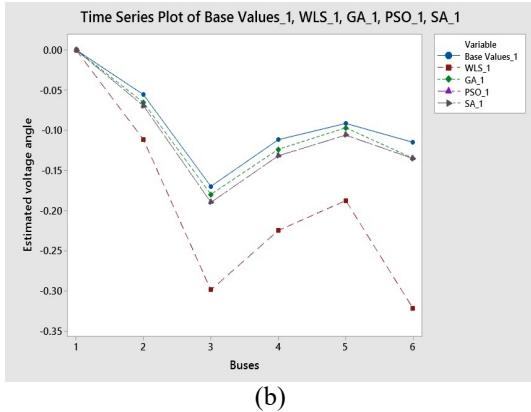
Figure 3(a) Comparative result of WLS, GA, PSO and SA state estimators for IEEE 6 bus test system with 2% variation in bounds in voltage magnitude. (b)Comparative result of WLS, GA, PSO and SA state estimators for IEEE 6 bus test system with 2% variation in bounds in voltage angle.
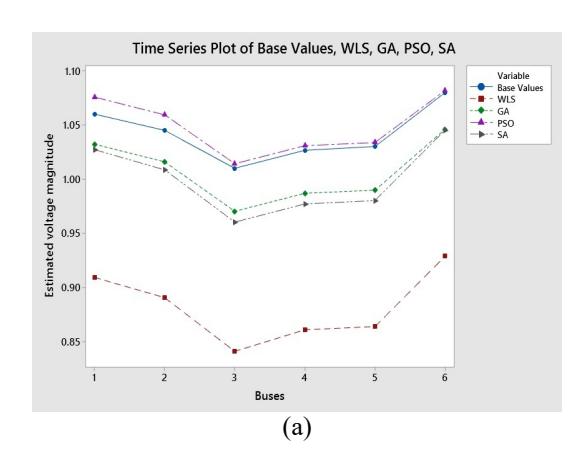
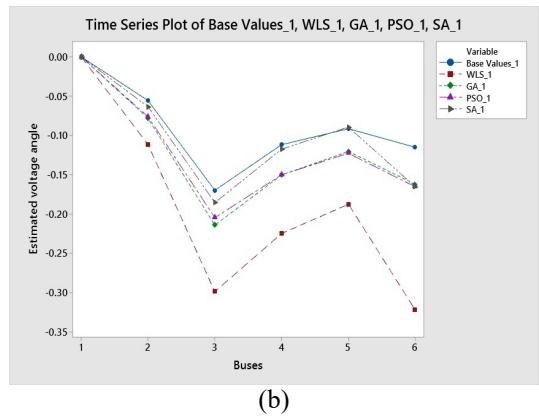
Figure 4(a) Comparative result of WLS, GA, PSO and SA state estimators for IEEE 6 bus test system with 5% variation in bounds in voltage magnitude. (b) Comparative result of WLS, GA, PSO and SA state estimators for IEEE 6 bus test system with 5% variation in bounds in voltage angles.
Tables 1 and 2 display the statistical summary of the percentage error for 2% and 5% variation in the bounds of the voltage magnitudes and angles, which include the average mean value of the percentage error, standard error, standard deviation, and variances. The percentage errors were calculated by comparing the voltage magnitudes and angles obtained from various state estimators to the base values obtained from the NR load flow analysis, and then using these percentage errors various statistical parameters have been computed.
Table 1. Statistical summary of percentage error for the IEEE 6 bus system with 2% variation in bounds
| WLS | GA with 2% variation in bounds | PSO with 2% variation in bounds | SA with 2% variation in bounds | |
|---|---|---|---|---|
| Mean | 59.443 | 5.586 | 8.667 | 8.606 |
| Standard | ||||
| Error | 17.027 | 2.031 | 2.721 | 2.738 |
| Standard | 56.475 | 6.739 | 9.025 | 9.082 |
| Deviation | 30.473 | 0.739 | 9.023 | 9.002 |
| Variance | 3189.476 | 45.418 | 81.456 | 82.492 |
Table 2. Statistical summary of percentage error for the IEEE 6 bus system with 5% variation in bounds
| GA with 5% | PSO with 5% | SA with 5% | |||
|---|---|---|---|---|---|
| WII C | |||||
| WLS | variation in | variation in | variation in | ||
| bounds | bounds | bounds | |||
| Mean | 59.443 | 17.607 | 15.771 | 8.966 | |
| Standard Error | 17.027 | 5.073 | 5.455 | 3.588 | |
| Standard | 56.475 | 16.825 | 18.092 | 11.901 | |
| Deviation | 30.473 | 10.823 | 18.092 | 11.901 | |
| Variance | 3189.476 | 283.074 | 327.353 | 141.624 | |
IEEE 14 Bus System
a. State Estimation Result
Figures 5(a) and 5(b) show the comparison of base values computed from Newton Raphson load flow analysis, WLS, GA, PSO, and SA state estimators to estimate the states of the standard IEEE 6 bus test system with a 2% variation in bounds, respectively, and Figures 6(a) and 6(b) show the 5% variation in bounds of voltage magnitudes and angles, respectively.
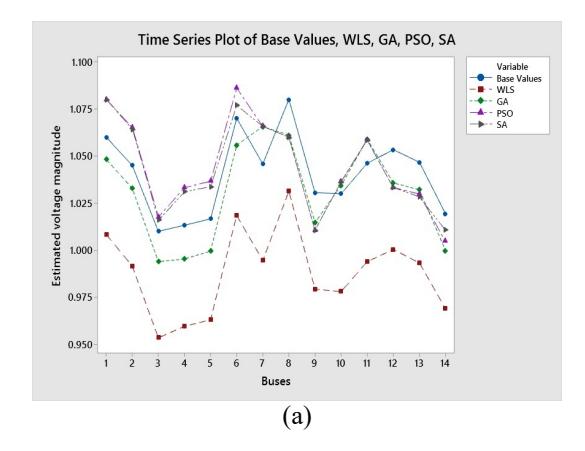
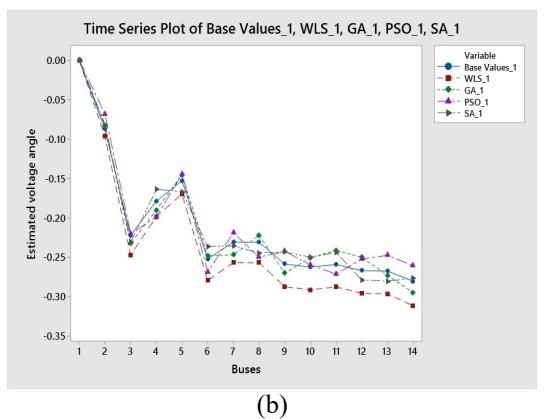
Figure 5(a). Comparative result of WLS, GA, PSO and SA state estimators for IEEE 14 bus test system with 2% variation in bounds in voltage magnitude. (b). Comparative result of WLS, GA, PSO and SA state estimators for IEEE 14 bus test system with 2% variation in bounds in voltage angle.
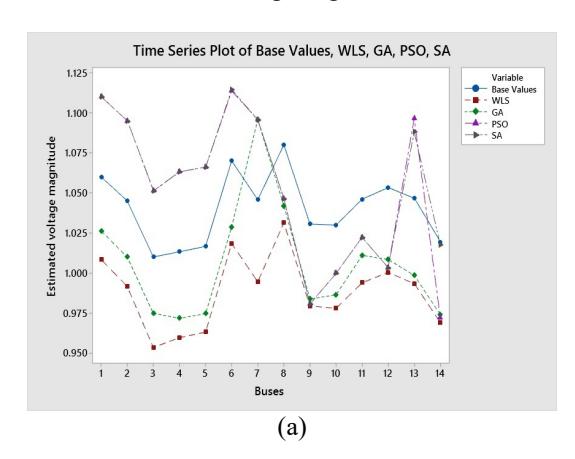
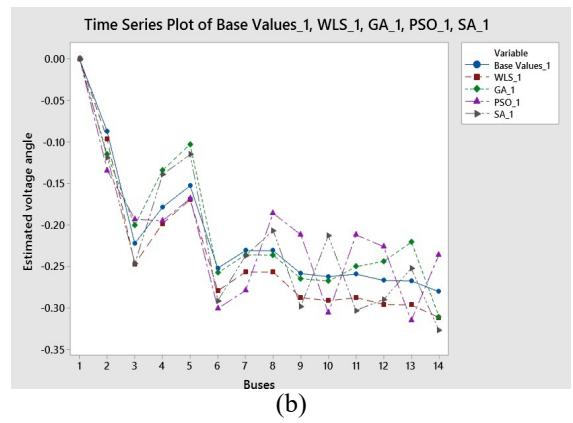
Figure 6(a). Comparative result of WLS, GA, PSO and SA state estimators for IEEE 14 bus test system with 5% variation in bounds in voltage magnitude. (b). Comparative result of WLS, GA, PSO and SA state estimators for IEEE 14 bus test system with 5% variation in bounds in voltage angle.
Tables 3 and 4 display the statistical summary of the percentage error for 2% and 5% variation in the bounds of the voltage magnitudes and angles, which include the average mean value of the percentage error, standard error, standard deviation, and variances.
Table 3. Statistical summary of percentage error for the IEEE 14 bus system with 2% variation in bounds
| WLS | GA with 2% variation in bounds | PSO with 2% variation in bounds | SA with 2% variation in bounds | |
|---|---|---|---|---|
| Mean | 7.880 | 3.061 | 4.198 | 3.309 |
| Standard Error | 0.582 | 0.396 | 0.849 | 0.481 |
| Standard Deviation | 3.023 | 2.056 | 4.415 | 2.497 |
| Variance | 9.142 | 4.230 | 19.497 | 6.238 |
Table 4. Statistical summary of percentage error for the IEEE 14 bus system with 5% variation in bounds
| WLS | GA with 5% variation in | PSO with 5% variation in | SA with 5% variation in | |
|---|---|---|---|---|
| bounds | bounds | bounds | ||
| Mean | 7.880 | 7.673 | 11.414 | 9.602 |
| Standard Error | 0.582 | 1.685 | 2.070 | 1.646 |
| Standard | 3.023 | 8.758 | 10.758 | 8.554 |
| Deviation | 3.023 | 0.738 | 10./38 | 0.334 |
| Variance | 9.142 | 76.716 | 115.736 | 73.176 |
IEEE 30 Bus System
a. State Estimation Result
Figures 7(a), 7(b), 8 (a) and 8(b) shows the comparison of base values computed from Newton Raphson load flow analysis, WLS, GA, PSO, and SA state estimators to estimate the states of the standard IEEE 6 bus test system with a 2% and 5% variation in bounds, respectively.
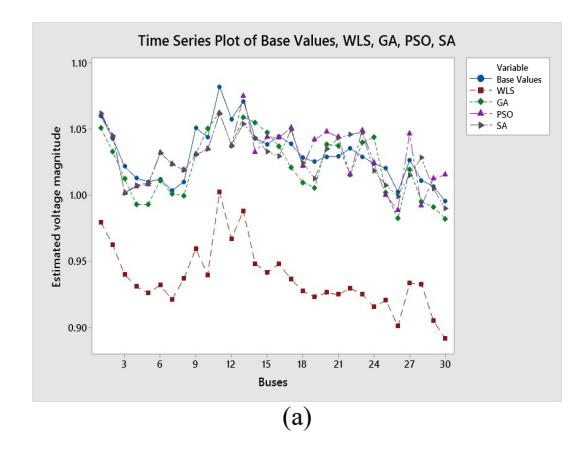
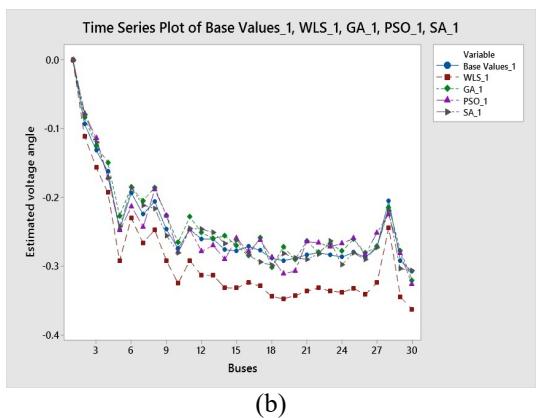
Figure 7(a). Comparative result of WLS, GA, PSO and SA state estimators for IEEE 30 bus test system with 2% variation in bounds in voltage magnitude. (b). Comparative result of WLS, GA, PSO and SA state estimators for IEEE 30 bus test system with 2% variation in bounds in voltage angle.
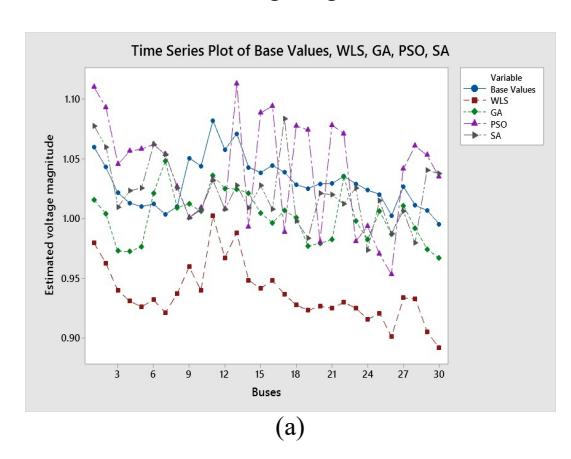
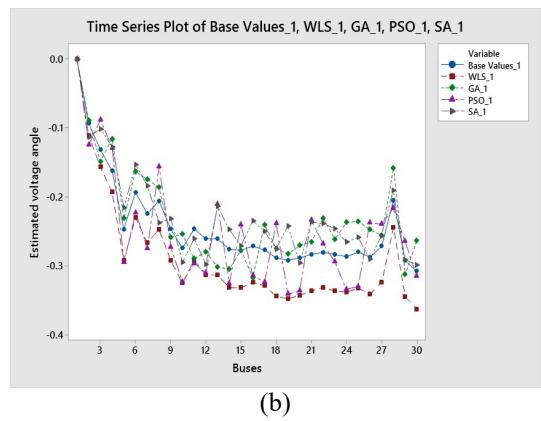
Figure 8(a). Comparative result of WLS, GA, PSO and SA state estimators for IEEE 30 bus test system with 5% variation in bounds in voltage magnitude. (b) Comparative result of WLS, GA, PSO and SA state estimators for IEEE 30 bus test system with 5% variation in bounds in voltage angle.
Tables 5 and 6 display the statistical summary of the percentage error for 2% and 5% variation in the bounds of the voltage magnitudes and angles, which include the average mean value of the percentage error, standard error, standard deviation, and variances.
Table 5. Statistical summary of percentage error for the IEEE 30 bus system with 2% variation in bounds
| WLS | GA with 2% | PSO with 2% | SA with 2% | |
|---|---|---|---|---|
| WLS | variation in bounds | variation in bounds | variation in bounds | |
| Mean | 13.879 | 3.194 | 3.578 | 2.477 |
| Standard Error | 0.658 | 0.364 | 0.456 | 0.345 |
| Standard Deviation | 5.056 | 2.800 | 3.507 | 2.656 |
| Variance | 25.572 | 7.844 | 12.306 | 7.058 |
Table 6. Statistical summary of percentage error for the IEEE 30 bus system with 5% variation in bounds
| WLS | GA with 5% | PSO with 5% | SA with 5% | |
|---|---|---|---|---|
| WLS | variation in bounds | variation in bounds | variation in bounds | |
| Mean | 13.879 | 7.276 | 10.266 | 6.830 |
| Standard | 0.658 | 0.835 | 1.037 | 0.823 |
| Error | 0.038 | 0.833 | 1.037 | 0.823 |
| Standard | 5.056 | 6.414 | 7.967 | 6.329 |
| Deviation | 3.030 | 0.414 | 7.907 | 0.329 |
| Variance | 25.572 | 41.140 | 63.477 | 40.057 |
Case 2- Missing data
This case deals with missing data in the state estimation using WLS, GA, PSO, and SA, where the measurement data between two buses has been missing.
IEEE 6 Bus System
a. State Estimation Results
Figure 9 (a) and figure 9 (b) depicts the comparative results of WLS, GA, PSO, and SA state estimators to estimate the states of the standard IEEE 6 bus test system when the real and reactive power flows between some buses have not been taken into consideration. The relative comparison of percentage error for all the techniques with missing measurement data is shown in Figure10
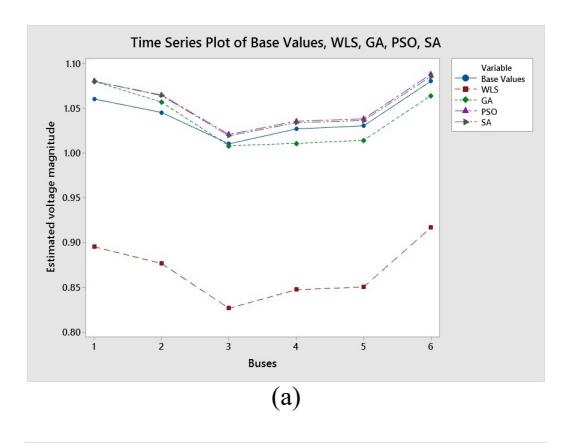
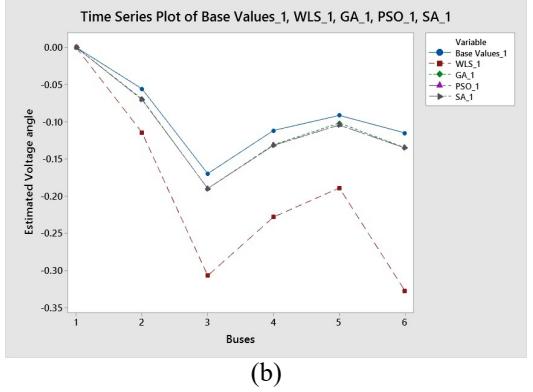
Figure 9(a). Comparative result of voltage magnitudes obtained using WLS, GA, PSO and SA state estimators for IEEE 6 bus test system with missing data (b). Comparative result of voltage angles obtained using WLS, GA, PSO and SA state estimators for IEEE 6 bus test system with missing data
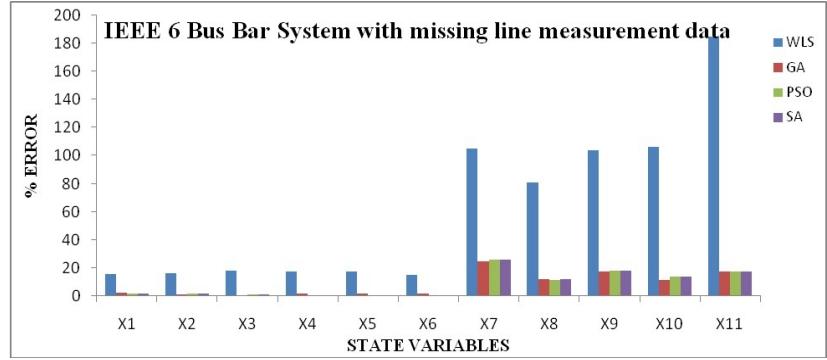
Figure 10. Perecntage error in the state variables using WLS, GA, PSO and SA estimators with missing line measurement data IEEE 6 bus system.
Tables 7 display the statistical summary of the percentage error when the real and reactive power flows between some buses have not been taken into consideration.
Table 7. Statistical summary of percentage error for the IEEE 6 bus system with missing data
| WLS | GA | PSO | SA | |
|---|---|---|---|---|
| Mean | 61.925 | 8.176 | 8.573 | 8.491 |
| Standard Error | 17.416 | 2.599 | 2.759 | 2.777 |
| Standard Deviation | 57.764 | 8.623 | 9.152 | 9.211 |
| Variance | 3336.707 | 74.353 | 83.756 | 84.850 |
IEEE 14 Bus System
a. State Estimation Results
Figure 11(a) and Figure 11 (b) depicts the comparative results of WLS, GA, PSO, and SA state estimators to estimate the states of the standard IEEE 14 bus test system when the real and reactive power flows between some buses have not been taken into consideration.
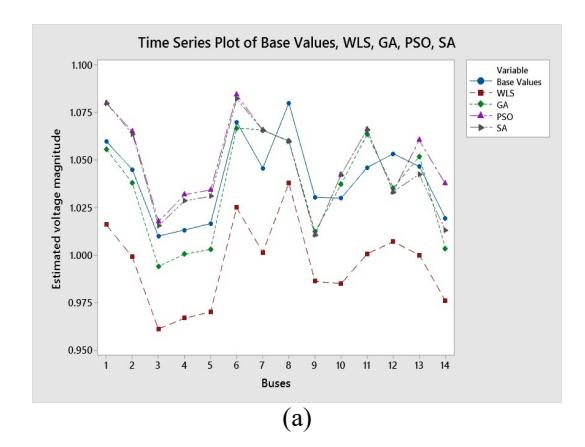
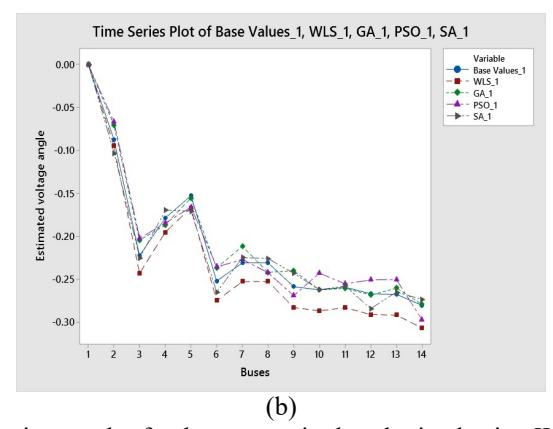
Figure 11(a). Comparative result of voltage magnitudes obtained using WLS, GA, PSO and SA state estimators for IEEE 14 bus test system with missing data (b). Comparative result of voltage angles obtained using WLS, GA, PSO and SA state estimators for IEEE 14 bus test system with missing data
The relative comparison of percentage error for all the techniques with missing measurement data is shown in Figure 12.
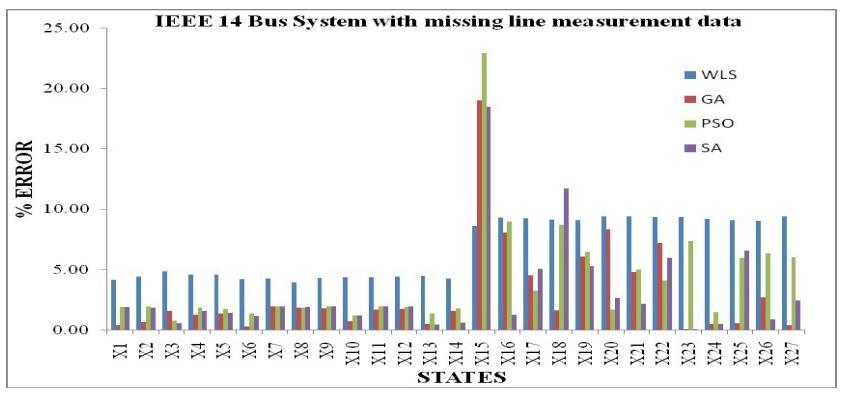
Figure 12. Perecntage error in the state variables using WLS, GA,PSO and SA estimators with missing line measurement data IEEE 14 bus system
b. Statistical Results
Tables 8 display the statistical summary of the percentage error when the real and reactive power flows between some buses have not been taken into consideration to incorporate the missing data effect. The results of the statistical analysis of variance using t-test (parametric test) with 95% confidence level are shown in Table 9.
Table 8. Statistical summary of percentage error for the IEEE 14 bus system with missing data
| WLS | GA | PSO | SA | |
|---|---|---|---|---|
| Mean | 6.685 | 3.002 | 4.131 | 3.063 |
| Standard Error | 0.476 | 0.776 | 0.867 | 0.763 |
| Standard | ||||
| Deviation | 2.475 | 4.032 | 4.507 | 3.966 |
| Variance | 6.127 | 16.256 | 20.319 | 15.732 |
Table 9. Statistical summary of t-Test on the IEEE 14 bus system with missing data
| WLS | GA | PSO | SA | |
|---|---|---|---|---|
| Mean | 0.9951 | 1.0348 | 1.0492 | 1.0453 |
| Variance | 0.0005 | 0.0007 | 0.0005 | 0.0005 |
| Observations | 14 | 14 | 14 | 14 |
| t Stat | 5.4538 | 0.6079 | -1.0502 | -0.5586 |
| P(T<=t) one tail | 5.09E-06 | 0.2743 | 0.1516 | 0.2906 |
| t Critical one tail | 1.7056 | 1.7081 | 1.7056 | 1.7056 |
IEEE 30 Bus System
a. State Estimation Results
Figure 13 (a) and Figure 13 (b) depicts the comparative results of WLS, GA, PSO, and SA state estimators to estimate the states of the standard IEEE 14 bus test system when the real and reactive power flows between some buses have not been taken into consideration.
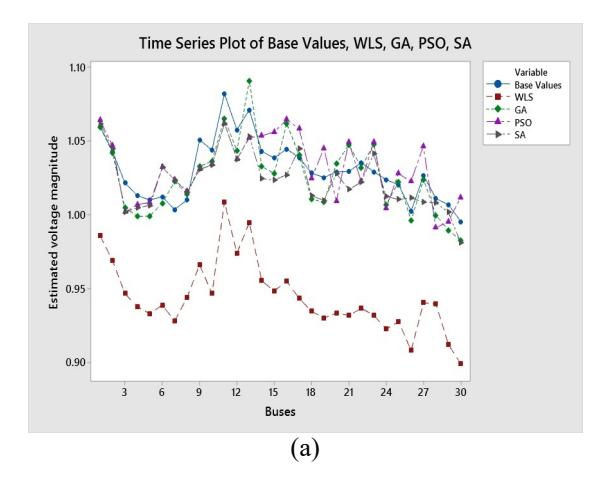
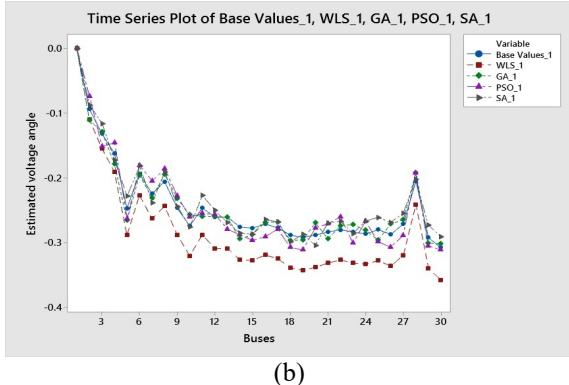
Figure 13(a). Comparative result of voltage magnitudes obtained using WLS, GA, PSO and SA state estimators for IEEE 30 bus test system with missing data. (b) Comparative results of voltage angles obtained using WLS, GA, PSO and SA state estimators for IEEE 30 bus test system with missing data
Tables 10 display the statistical summary of the percentage error when the real and reactive power flows between some buses have not been taken into consideration. The results of the statistical analysis of variance using t-test (parametric test) with 95% confidence level are shown in Table 11.
Table 10. Statistical summary of t-Test on the IEEE 30 bus system with missing data
| WLS | GA | PSO | SA | |
|---|---|---|---|---|
| Mean | 12.750 | 2.719 | 4.043 | 3.006 |
| Standard Error | 0.596 | 0.398 | 0.496 | 0.344 |
| Standard Deviation | 4.581 | 3.058 | 3.815 | 2.646 |
| Variance | 20.983 | 9.354 | 14.553 | 7.001 |
| Table 11. Statistical summary of t-Test on the IEEE 30 bus system with missing data | ||
|---|---|---|
| WLS | GA | PSO | SA | |
|---|---|---|---|---|
| Mean | 0.9440 | 1.0260 | 1.0315 | 1.0230 |
| Variance | 0.0005 | 0.0006 | 0.0004 | 0.0003 |
| Observations | 30 | 30 | 30 | 30 |
| t Stat | 14.7320 | 0.6892 | -0.2559 | 1.3793 |
| P(T<=t) one-tail | 2.1616E-21 | 0.2467 | 0.3994 | 0.0865 |
| t Critical one-tail | 1.6720 | 1.6725 | 1.6715 | 1.6720 |
Case 3- Infringed data
State Estimation using WLS, GA, PSO, and SA with infringed data. These cases are considered for evaluating the efficiency and robustness of the algorithms.
IEEE 6 Bus System
a. State Estimation Results
Figure 14 (a) and Figure 14(b) depicts the comparative results of WLS, GA, PSO and SA state estimators to estimate the states of the standard IEEE 6 bus test system when some infringement with the measurement data has been done in the system.
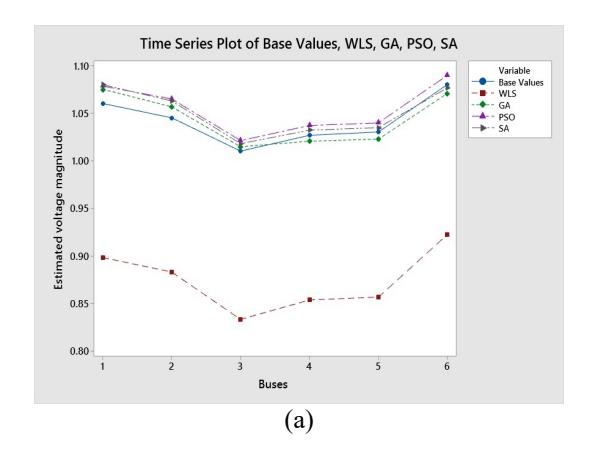
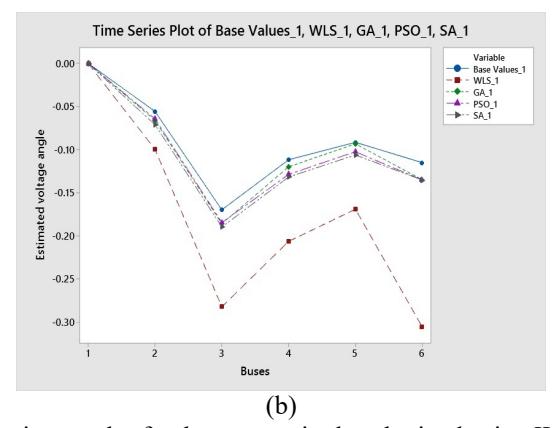
Figure 14(a). Comparative result of voltage magnitudes obtained using WLS, GA, PSO and SA state estimators for IEEE 6 bus test system with infringed data (b). Comparative result of voltage angles obtained using WLS, GA, PSO and SA state estimators for IEEE 6 bus test system with infringed data
The relative comparison of percentage error for all the techniques with missing measurement data is shown in Figure 15.
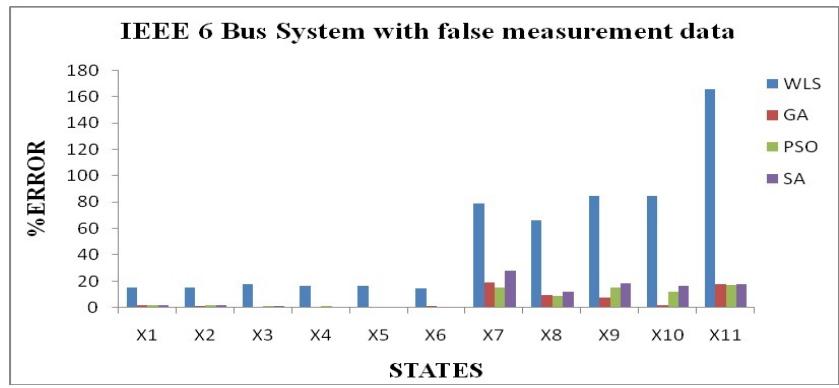
Figure 15. Perecntage error in the state variables using GA, PSO and SA state estimators with infringed data in IEEE 6 bus system
b. Statistical Results
Tables 12 display the statistical summary of the percentage error when the measurement data has been infringed.
| Table 12. Statistical summary of percentage error for the IEEE 6 but | us |
|---|---|
| system with infringed data |
| , | 0 | |||
|---|---|---|---|---|
| WLS | GA | PSO | SA | |
| Mean | 52.423 | 5.469 | 6.927 | 8.772 |
| Standard Error | 14.683 | 2.089 | 2.066 | 2.938 |
| Standard Deviation | 48.699 | 6.930 | 6.854 | 9.745 |
| Variance | 2371.64 | 48.026 | 46.978 | 94.977 |
IEEE 14 Bus System
a. State Estimation Results
Figure 16 (a) and Figure 16 (b) depicts the comparative results of WLS, GA, PSO, and SA state estimators to estimate the states of the standard IEEE 14 bus test system when some infringement with the measurement data has been done in the system. The relative comparison of percentage error for all the techniques with missing measurement data is shown in Figure 17.
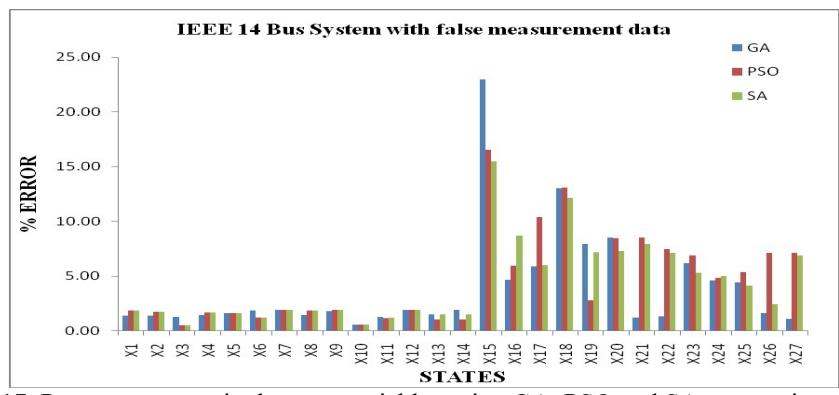
Figure 17. Percentage error in the state variables using GA, PSO and SA state estimators with infringed data in IEEE 14 bus system
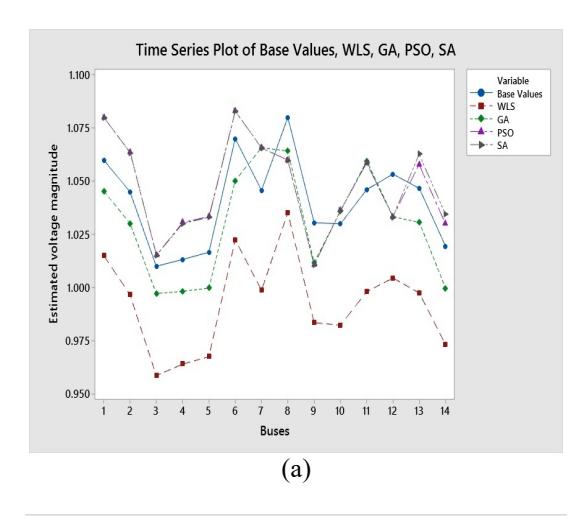
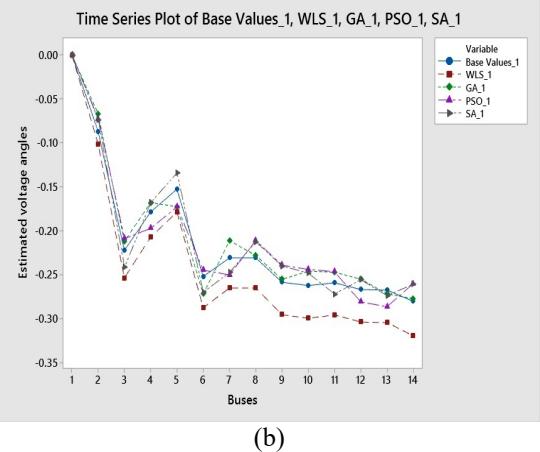
Figure 16(a). Comparative result of voltage magnitudes obtained using WLS, GA, PSO and SA state estimators for IEEE 14 bus test system with infringed data. (b). Comparative result of voltage angles obtained using WLS, GA, PSO and SA state estimators for IEEE 14 bus test system with infringed data
Tables 13 display the statistical summary of the percentage error when the measurement data has been infringed and Table 14 shows the results of statistical analysis through t- test with 95% confidence level.
Table 13. Statistical summary of percentage error for the IEEE 14 bus system with infringed data
| WLS | GA | PSO | SA | |
|---|---|---|---|---|
| Mean | 9.4628 | 3.8881 | 4.6240 | 4.3258 |
| Standard Error | 1.0003 | 0.9258 | 0.8027 | 0.7274 |
| Standard Deviation | 5.1976 | 4.8108 | 4.1713 | 3.7800 |
| Variance | 27.0155 | 23.1440 | 17.3997 | 14.2886 |
Table 14. Statistical summary of t-Test on the IEEE 14 bus system with infringed data
| WLS | GA | PSO | SA | |
|---|---|---|---|---|
| Mean | 0.9926 | 1.0301 | 1.047 | 1.0476 |
| Variance | 0.0005 | 0.0006 | 0.0005 | 0.0005 |
| Observations | 14 | 14 | 14 | 14 |
| t Stat | 5.7331 | 1.1665 | -0.7811 | -0.8520 |
| P(T<=t) one-tail | 2.45E-06 | 0.1272 | 0.2208 | 0.2009 |
| t Critical one- tail | 1.7056 | 1.7081 | 1.7056 | 1.7056 |
IEEE 30 Bus System
a. State Estimation Results
Figure 18 (a) and Figure 18 (b) depicts the comparative results of WLS, GA, PSO, and SA state estimators to estimate the states of the standard IEEE 14 bus test system when some infringement with the measurement data has been done in the system.
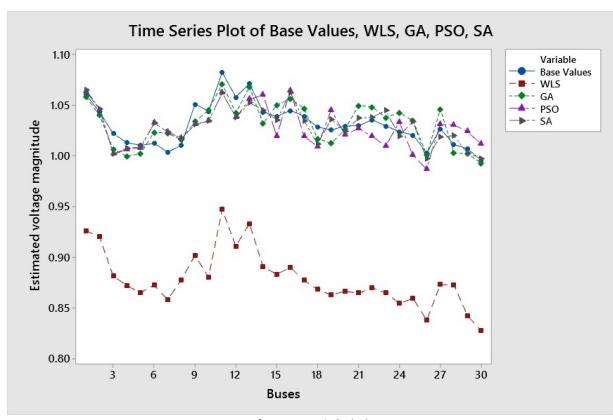
Figure 18(a).
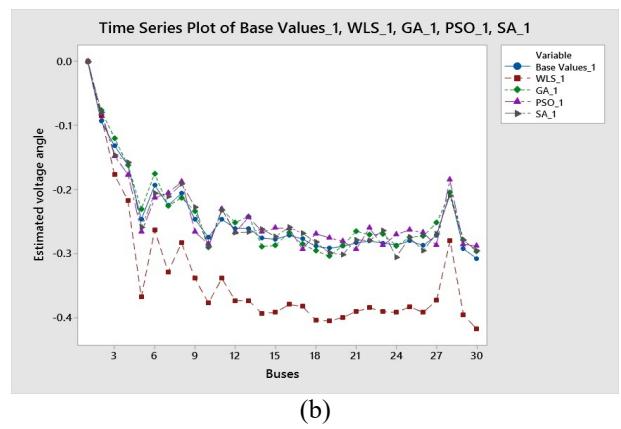
Figure 18(a). Comparative result of voltage magnitudes obtained using WLS, GA, PSO and SA state estimators for IEEE 30 bus test system with infringed data. (b). Comparative result of voltage angles obtained using WLS, GA, PSO and SA state estimators for IEEE 30 bus test system with infringed data.
Tables 15 and Table 16 display the statistical summary and statistical analysis of variance using a t-test with a 95% confidence interval of the percentage error respectively when the measurement data has been infringed.
Table 15. Statistical summary of percentage error for the IEEE 30 bus system with infringed data
| WLS | GA | PSO | SA | |
|---|---|---|---|---|
| Mean | 25.986 | 2.741 | 3.878 | 2.727 |
| Standard Error | 1.616 | 0.406 | 0.423 | 0.370 |
| Standard Deviation | 12.416 | 3.117 | 3.252 | 2.845 |
| Variance | 154.171 | 9.719 | 10.578 | 8.093 |
Table 16. Statistical summary of t-Test on the IEEE 30 bus system with infringed data
| WLS | GA | PSO | SA | |
|---|---|---|---|---|
| Mean | 0.8782 | 1.0305 | 1.0276 | 1.0291 |
| Variance | 0.0007 | 0.0004 | 0.0004 | 0.0003 |
| Observations | 30 | 30 | 30 | 30 |
| t Stat | 24.1669 | -0.0732 | 0.4831 | 0.1940 |
| P(T<=t) one-tail | 6.24E-31 | 0.4709 | 0.3154 | 0.4234 |
| t Critical one-tail | 1.6735 | 1.6715 | 1.6715 | 1.6720 |
4. Result and Discussion
In this paper, WLS, GA, PSO, and SA methods are utilized to find the comparative optimum solution of the state estimation problem. The chosen strategies have been tried on three standard IEEE test systems to test their optimization performances. The results of the particular procedures are looked at in comparison to the results reported in [13] and [23] and the outcomes of the optimization are analyzed.
The outcomes are also analysed on the following basis:
- Variation of percentage error with the variation in the bounds of the voltage magnitudes and angles.
- Variation of percentage error when the measurement data between some buses has not been taken into consideration.
- Variation of statistical error when measurement data has been infringed.
Statistical Analysis of the various techniques has also been done and the robustness of the algorithms has also been cross checked by the parametric t-test.
Analysis of all the techniques gives following result:
1. Variation of percentage error with the variation in the bounds
State Estimation Result Analysis
• For IEEE 6 bus system the average percentage error with WLS state estimator comes out to be 59.44%. With GA, PSO, and SA state estimators the average error is 5.59%, 8.67%, and 8.61% respectively for 2% variation in bounds whereas for 5% variation in bounds the percentage error for GA, PSO, and SA increases to 17.61%, 15.77%, and 8.97% respectively.
- For IEEE 14 bus system the average percentage error with WLS state estimator comes out to be 7.88%. With GA, PSO, and SA state estimators the average error is 3.06%, 4.20%, and 3.31% respectively for 2% variation in bounds whereas for 5% variation in bounds the percentage error for GA, PSO, and SA increases to 7.67 %, 11.41%, and 9.60% respectively.
- For IEEE 30 bus system the average percentage error with WLS state estimator comes out to be 13.88%. With GA, PSO, and SA state estimators the average error is 3.19%, 3.58%, and 2.47% respectively for 2% variation in bounds whereas for 5% variation in bounds the percentage error for GA, PSO, and SA increases to 7.28%, 10.27%, and 6.63% respectively.
Statistical Result Analysis
- State estimation using WLS, GA, PSO, and SA is performed on the all the three systems i.e IEEE 6, 14 bus and 30 bus systems bus system considering variations of 2% and 5% in the upper and the lower bounds of the probable optimal solution for GA, PSO and SA. On analyzing the results of statistical summary from it is found that the Mean value of percentage error, Standard Error, Standard Deviation and Variance is lowest in GA state estimator with 2% variation in the bounds. It is also seen that as the variation in the bounds increase the percentage error in the system also increases.
- 2. Variation of percentage error when the measurement data between some buses is not taken into consideration
State Estimation Result Analysis
- For IEEE 6 bus system the average percentage error with WLS state estimator when the measurement data for some buses has not been considered comes out to be 61.92% whereas with GA, PSO, and SA state estimators the average error is 8.18%, 8.57%, 8.49% respectively.
- For IEEE 14 bus system the average percentage error with WLS state estimator when the measurement data for some buses has not been considered comes out to be 6.68% whereas with GA, PSO, and SA state estimators the average error is 3.00%, 4.13%, 3.06% respectively.
- For IEEE 30 bus system the average percentage error with WLS state estimator when the measurement data for some buses has not been considered comes out to be 12.75% whereas with GA, PSO, and SA state estimators the average error is 2.71%, 4.04%, and 3.0% respectively.
Statistical Result Analysis
- In the case of the missing measurement data for all the three test systems, the results of the statistical summary are clearly showing that the Mean value of percentage error, Standard Error, Standard Deviation and Variance is the lowest in the GA state estimator.
- 3. Variation of percentage error when measurement data has been infringed State Estimation Result Analysis
- For IEEE 6 bus system the average percentage error with WLS state estimator when the measurement data is infringed comes out to be 52.42% whereas with GA, PSO, and SA state estimators the average error is 5.47%, 6.93%, and 8.77% respectively.
- For IEEE 14 bus system the average percentage error with WLS state estimator when the measurement data is infringed comes out to be 9.46% whereas with GA, PSO, and SA state estimators the average error is 3.89%, 4.62%, and 4.32% respectively.
• For IEEE 30 bus system the average percentage error with WLS state estimator when the measurement data is infringed comes out to be 25.99% whereas with GA, PSO, and SA state estimators the average error is 2.74%, 3.88%, and 2.73% respectively.
Statistical Result Analysis
• In the case of the infringed measurement data for IEEE 6, 14, and 30 bus test systems, the statistical summary clearly shows that the GA state estimator has the lowest Mean value of percentage error, Standard Error, Standard Deviation, and Variance.
Parametric test results
To access the robustness of the evolutionary algorithms t-test is also performed on the IEEE 14 and 30 bus systems for the condition of the contingency and data infringement. When analyzing the results of the t-test with missing line measurements and with infringed data, it is found that the value of t-stat is less than t-critical in both GA, PSO, and SA state estimators, whereas it is greater in WLS, indicating that there is a significant difference between base and estimated values in WLS, but no significant difference between base and estimated values in GA, PSO, and SA state estimators
5. Conclusion
On critically analyzing the results it is found that the GA-based state estimation strategy proves to be more reasonable for state estimation investigation as the average percentage error in GA is very small for all the test systems when contrasted with the WLS-SE method, PSO based SE technique and SA based SE technique. The GA-based state estimation technique is also more robust and efficient for power system state estimation, according to the statistical analysis and parametric t-test results. As a result of the error analysis study using statistical parameters, we can conclude that the GA-based state estimation technique is a more suitable SE procedure than the other strategies.
6. References
- 1. F. C. Schweppe, J. Wildes, and D. B. Rom, "Power system static state estimation", part I, II, III. IEEE Transactions on Power Apparatus and Systems, vol. PAS-89, no. 1, pp. 120–135, Jan. 1970.
- 2. A. Abur and A. G. Exposito, "Power System State Estimation: Theory and Implementation", New York: Marcel Dekker, 2004.
- 3. A. Monticell, "State Estimation in Electric Power System: A Generalized Approach", Norwell, MA: Kluwer, 1999.
- 4. B. Fardanesh, "Method and systems for power systems analysis: A non-iterative state solver/estimator for power systems operation and control", U.S. Patent 20 050 160 128. 2012.
- 5. B. Fardanesh, "Direct non-iterative power system state solution and estimation", Power and Energy Society General Meeting IEEE, San Diego, CA, pp. 1–6, 2012.
- 6. X. T. Jiang, B. Fardanesh and M. Razanousky, "Power System State Estimation using a Direct Non-Iterative Method", International Journal of Electrical Power & Energy Systems, , vol.73, pp. 361-368, December 2015.
- 7. R. Ebrahimian and R. Baldick, "State estimator condition number analysis", IEEE Transactions on Power System, vol. 16, no. 2, pp. 273–279, May 2001.
- 8. Y. Guo, W. Wu, B. Zhang, and H. Sun, "A distributed state estimation method for power systems incorporating linear and nonlinear models", International Journal of Electrical Power & Energy Systems, vol.64, pp.608–616, 2015.
- 9. M. M. Nordman and M. Lehtonen, "Distributed agent-based State estimation for electrical distribution networks", IEEE Transactions on Power System, vol. 20, no. 2, pp. 652–658, May 2005.
- 10. A. J. Conejo, S. Torre, M. Cañas, "An Optimization Approach to Multi area State Estimation", IEEE Transactions on Power Systems, vol. 22, no. 1, February 2007.
- 11. A. R. Reeves, "Modern Heuristic Techniques for Combinatorial Problems", Blackwell Scientific Publications, Oxford, 1993.
- 12. P. W. Tsai, J. S. Pan, B. Y. Liao and S.C. Chu, "Enhanced artificial bee colony optimisation", International Journal of Innovative Computing, Information and Control, vol.5, no.12, pp. 1-12, 2009.
- 13. A. A. Hossam-Eldin, E. N. Abdallah, and M. S. El-Nozahy, "A Modified Genetic Based Technique for Solving the Power System State Estimation Problem", International Journal of Electrical and Computer Engineering, vol. 3, no. 7, pp. 1438-1447, 2009.
- 14. M. Aien, M. Rashidinejad, S. Kouhi, M. Fotuhi-Firuzabad and S N. Ravadanegh, "Real time probabilistic power system state estimation", International Journal of Electrical Power and Energy Systems, vol.62, pp.383–390 2014.
- 15. S. Goleijani and M. T. Ameli, "Neural network-based power system dynamic state estimation using hybrid data from SCADA and phasor measurement units", Int Trans Electr Energy Syst, vol. 28, no. 2, 2018.
- 16. A. Rankovi, B.M. Maksimovi, A.T. Sari, U. Lukic, "ANN-based correlation of measurements in micro-grid state estimation", Int Trans Electr Energy Syst, vol. 25, no. 10, pp. 2181-2201, 2015.
- 17. E. T. Ghadikolaee, A. Kazemi and H.A. Shayanfar, "Multi-area state estimation in a distribution network using Takagi-Sugeno model estimated by Kalman filter", Int Trans Electr Energy Syst, vol. 30, no. 8, 2020.
- 18. M. B. Do Coutto Filho, J.C. de Souza, J. D. Glover, "Roots, achievements, and prospects of power system state estimation: a review on handling corrupted measurements", Int Trans Electr Energy Syst, vol. 29, no. 4, 2019.
- 19. D. Mukherjee, S. Chakraborty, S. Ghosh and R. K. Mishra, "Application of deep learning for power system state forecasting", Int Trans Electr Energ Syst, doi.org/10.1002/2050-7038.12901, 2021.
- 20. S. Mallik, S. P. Ghoshal, P. Acharjee and S. S. Thakur, "Optimal static state estimation using improved particle swarm optimisation and gravitational search algorithm", International Journal of Electrical Power & Energy Systems, vol. 52, pp. 254-265, 2013.
- S. Naka, T. Genji, T. Yura, Y. Fukuyama, "A hybrid particle swarm optimization for distribution state estimation, IEEE Transactions on Power System, vol. 18, no.1, pp. 60-68, 2003.
- 22. L. Holten, A. Gjelsvik, S. Aam, F. Wu and W. H. E. Liu, "Comparison of different methods for state estimation," IEEE Transactions on Power System, vol. 3, no. 4, pp. 1798–1806, 1988.
- 23. D. H. Tungadio, J. A. Jordaan and M.W. Siti, "Power system state estimation solution using modified models of PSO algorithm: Comparative study", Measurement, vol. 92, pp. 508–523, 2016.
- 24. M. Pramanik, A. Routray and P. Mitra, "State Estimation of Power System Signal using Constrained Optimized Algorithms-Comparative Analysis", 14th IEEE India Council International Conference (INDICON), 2017.
- 25. R. Dutta, A. Dubey, S. Chakrabarti and A. Sharma, "Comparative Performance Analysis of Optimization Based Distribution System State Estimator with Varying Measurement Uncertainties", 20th National Power Systems Conference (NPSC), 2018.
- 26. D. Gotti, P. Ledesma and H. Amaris, "Comparative Analysis between State Estimation Algorithms under Static and Dynamic Scenarios", IEEE International Conference on Environment and Electrical Engineering and IEEE Industrial and Commercial Power Systems Europe (EEEIC / 1&CPS Europe), 2020.
- 27. L. Kumar and P. K. Kherdikar, "An overview of different static state estimation techniques with bad data detection, identification and elimination in power system",
- International Journal of Ambient Energy, doi.org/10.1080/01430750.2021.1874524, 2021.
- 28. R. L. Fagbenle, "A statistical analysis of global solar radiation measurements at two sites in Ibadan, Nigeria", International Journal of Ambient Energy, vol. 15, no. 2, doi.org/10.1080/01430750.1994.9675636, 1994.
- 29. R. Eberhart and J. Kennedy, "A new optimizer using particle swarm theory", Proc. 6th Int. Symp. Micro Machine Human Science, pp. 39 - 43, 1995,
- 30. H. Xiaohui, S. Yuhui, and R. Eberhart, "Recent advances in particle swarm", Proceedings of the Congress of Evolutionary Computation, vol. 1, pp. 90–97, 2004.
- 31. Y. Shi and R. Eberhart, "A modified particle swarm optimizer", Evolutionary Computation Proceedings, IEEE World Congress on Computational Intelligence, pp. 69– 73, 1998.
- 32. M.R. AlRashidi, M.E. El-Hawary, "A survey of particle swarm optimization applications in electric power system", IEEE Transaction on Evolutionary Computations, vol.13, no.4, pp. 913 – 918, 2009
- 33. K.V. K Kavuturu and P.V.R.L Narasimham, "Optimization of Transmission System Security Margin under (N-1) Line Contingency Using Improved PSO Algorithm", International Journal on Electrical Engineering and Informatics – Vol. 12, No. 2, June 2020.
- 34. Z. Ullah, M.R. elkadeem , S. Wang and J. Radosavljevi "A Novel PSOS-CGSA Method for State Estimation in Unbalanced DG-Integrated Distribution Systems", IEEE Access, June 2020.
- 35. http://www.ee.washinton.edu/ research/pstca.
Pankhuri Kishore is a PhD scholar in the Electronics and Communication Engineering Department of Amity School of Engineering and Technology, Amity University Uttar Pradesh Lucknow Campus, India. She received her M.Tech. degree in Electrical Engineering from National Institute of Technology, Hamirpur in 2011. She completed her B.Tech. degree in Electrical Engineering from M.M.M Engineering College, Gorakhpur, Uttar Pradesh, India in 2009. She is currently working as Lecturer in the Electrical Engineering Department of Government Polytechnic, Kursi Road,
Barabanki. Her research interest includes power system operation and planning.
Stuti Shukla Datta received the B.Tech. degree in electrical engineering from Uttar Pradesh Technical University, Lucknow, India, in 2004; the M.Eng. degree in power systems from the Birla Institute of Technology Mesra, Ranchi, India, in 2007; and the Ph.D. degree in power quality assessment and improvement from the Indian Institute of Technology Delhi, New Delhi, India, in 2014. Dr. Shukla received the Power System Operation Corporation (POSOCO) Power System Award in 2014.
Seethalekshmi K. received her B.Tech. in Electrical Engineering from Calicut, Kerala, India, M.tech in power system from College of Engineering, Trivandrum, Kerala, India and completed her Ph.D. from Indian Institute of Technology, Kanpur, India. Currently she is working as Professor in the Department of Electrical Engineering IET, Lucknow. Her research interests include wide-area power system stability and protection.
Anil Kumar Graduated in Electrical and Electronics Engineering B.E. from Thapar University Patiala with Honours. Master of Engineering with Distinction from Pune University in Guidance and Control M Sc in Strategic Studies with First Class Distinction from Madras University Ph.D. in Electrical Engg from NIT Allahabad (Erstwhile Motilal Nehru Regional Engg College) in Grade 1 (Top grade) Area of Specialisation Advance Control System. Rich work experience of 24 years in operation of Radar System, Analog and Digital Communication, Power Systems, Missile Design
Control and Guidance System in Indian Air Force as Wing Commander. He is currently working as Assistant Pro Vice Chancellor and Director, Amity School of Engineering & Technology, Lucknow.