Haritha Guddeti1 and Kannan A.2
1 Research Scholar, Department of Electrical and Electronics Engineering, DR.M.G.R Educational and Research Institute (Deemed to be university), Maduravoyal, Chennai, India. Assistant Professor, EEE Department, G. Pulla Reddy Engineering College (Autonomous), Kurnool, Andhar Pradesh, India
2 Professor, Department of Electrical and Electronic Engineering, DR.M.G.R Educational and Research Institute (Deemed to be university), Maduravoyal, Chennai, India gharitha804@gmail.com
Abstract: Maintaining frequency stability in modern power systems is a critical challenge, especially in deregulated environments where diverse generating sources, such as renewable and conventional units, operate under market-driven conditions. In this study, a Tilt Integral Derivative (TID) controller is proposed for Automatic Generation Control (AGC) in a multiarea power system integrating solar-thermal units. The primary objective is to enhance system stability while accounting for key nonlinearities, such as Generation Rate Constraints (GRCs) and Governor Dead Band (GDB), which significantly affect dynamic performance. To optimally tune the TID controller parameters, we employ the Cuttlefish Optimization Algorithm (COA), a novel bio-inspired optimization approach. The effectiveness of the COAbased TID controller is assessed by comparing its performance with other established optimization techniques, including the Grey Wolf Optimization (GWO) algorithm. Key performance metrics, such as peak overshoot (PO), peaks undershoot (PU), and settling time (ST), are analyzed under varying load disturbances. Simulation results demonstrate that the COA-optimized TID controller outperforms competing methods, providing superior frequency stability, faster response times, and reduced oscillations in an open-market power system. The findings establish COA as a robust alternative for AGC tuning, particularly in systems with high renewable energy penetration and deregulated operation.
Keywords: TID controller; Automatic Generation and Control; Deregulation; Cuttlefish Optimization Algorithm; DISCO participation matrix.
1. Introduction
Frequency is a critical aspect of power systems. Recently, the frequency of regulation in power systems has often enchanted research concerns. Every power plant needs to keep an eye on how much energy is consumed during the day sorted out to match the ever-rising constraints of its customers for excellent service. Because there is never a steady energy source, load disturbances are used to reduce power fluctuations at different times of the day. Under the current conditions, it is essential to guarantee a consistent and affordable electrical supply while effectively distributing power through a connected device consistently and affordably. Load disturbances significantly impact machine power supply frequency, while reactive power exhibits variable responses to changes in voltage and current conditions.
Moreover, the community's structure will get increasingly complex as more sites are linked together through the process of linking traces. The magnetizing current will persist to increase in strength, even with a little decrease in frequency. Both the transformer and the coil may experience exhaustion or fatigue due to the increasing electrical current passing through it. In the current setting, it is difficult to maintain a steady electric system due to the increased power consumption. During operation, electrical equipment has a continuous change in weight. This device's principal task is to guarantee the necessary level of stability and robustness in the electrical machinery. The generator's mechanical output strain is inversely correlated with the tool's frequency[1-4].
Received: September 2nd, 2024. Accepted: March 26th, 2025
DOI: 10.15676/ijeei.2025.17.1.4
The concept of frequency regulation encompasses three separate levels, namely primary, secondary, and tertiary. The primary frequency control loop detects a decrease in frequency prior to the activation of the relays that protect against under/over frequency. The utilization of the governor droop is a common practice in primary frequency control, resulting in chronically recorded inaccuracies. The regulation of frequency in power systems is the responsibility of secondary frequency control, which is also referred to as AGC or LFC. The main goals of this system are to maintain the frequency within a specified range and to effectively regulate the transmission of power between control regions through significant tie lines [5-7].
The primary target of the single-area LFC system is to achieve control over the operating frequency, ensuring that it remains at its nominal value without requiring any adjustments to the interconnected system. To achieve load balancing in a multi-area load factor correction (LFC) system, it is necessary for the generators in each area to effectively handle both the local load and the power fluctuations on the tie lines that connect several regions [8-10]. The frequency management method entails the integration of the ACE signal into the feedback loop. This approach not only considers fluctuations in voltage and frequency transfer but also addresses the mistakes in energy and time resulting from irregularities in schedules and devices [11-13].
The Genetic Algorithm (GA) is employed to optimise data by adjusting the parameters of a discrete PI controller [14]. A graphical method is used to tweak the proportional-integral (PI) controller settings for a single-area LFC system with a time delay in order to achieve stability. A crucial aspect of the technique is the determination of the stability boundary locus. The validity and efficacy of the recommended technique are demonstrated using time-domain simulations. The stability region is depicted within the parameter space of the controller [15]. Fuzzy gain scheduling of PI controllers is employed for load frequency management in multipower systems [16-17]. The performance of LFCs is influenced by nonlinear parameters such as the GDB and GRC [18–19]. Various methodologies, including as Firefly, HGS and COA, have been examined to enhance controller configurations [20-22]. The management of AGC in multi-area systems is facilitated through the utilization of a PID controller [23-24].In multiarea systems, the management of AGC is facilitated through the utilization of a TID controller [25-27].
2. Multi Area Power System
The AGC system consists of two power plants: a thermal unit and a solar unit, as depicted in Figure 1, each consisting of two GENCOs and DISCOMS.
A. Conventional Electric power system scenario
The conventional electricity market comprises utilities that possess and manage their own power infrastructure. The public service exercises complete control over every aspect of production and delivery. Utilities possess and control the infrastructure and electrical lines, which they directly sell to consumers. Utilities are required to adhere to the electricity pricing established by the state utility council. This market is commonly referred to as a monopoly because it offers limited options for consumers. Nevertheless, its benefits encompass consistent pricing and enduring stability.
B. Deregulated power system scenario
Deregulation, as applied within the electrical sector, refers to the procedure of amending the governing rules and regulations to increase the number of energy providers available to consumers. Customers and energy dealers are permitted to allocate their funds as they see appropriate toward the expansion and maintenance of electricity transmission and generation systems in a deregulated electrical zone. A significant portion of the electricity generated by the Genco assets is distributed through retail utility infrastructure. The capacity to evaluate and contrast costs and services, in addition to the implementation of probability-based methodologies, are both advantageous for customers.
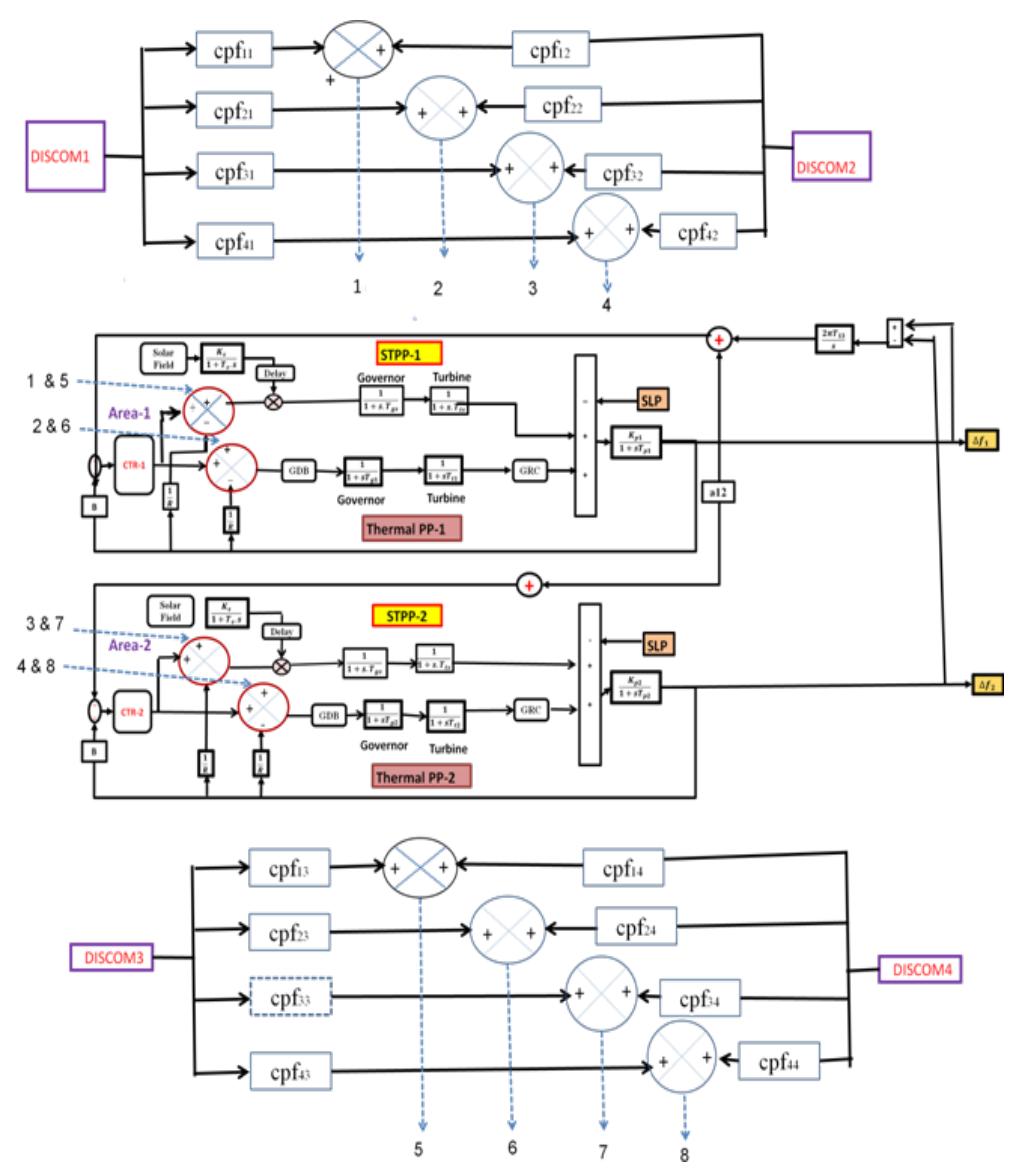
Figure 1. Two area Solar-Thermal restructured power system block diagram
∆Ptie − ,21 scheduled = (Total required load of Disco's in second area from first area in the Genco's) – (Total required load of Disco's in first area from second area in the Genco's) (1)
\[\Delta P_{tie1-2,scheduled} = \Delta P_{tie1-2,error} + \Delta P_{tie1-2,actual} \tag{2}\]
\[e_1(t) = ACE_1 = B_1 \Delta f_1 + \Delta P_{tiel-2,error}\] (3)
\[e_2(t) = ACE_2 = B_2 \Delta f_2 + \Delta P_{tie2-1,error}\] (4)
C. Disco Participation Matrix (DPM)
Each column in the DPM must have a total value of unity for Genco to provide the required load to the disco regardless of the region or condition.
\[DPM = \begin{bmatrix} cpf_{11} & cpf_{12} & cpf_{13} & cpf_{14} \\ cpf_{21} & cpf_{22} & cpf_{23} & cpf_{24} \\ cpf_{31} & cpf_{32} & cpf_{33} & cpf_{34} \\ cpf_{41} & cpf_{42} & cpf_{43} & cpf_{44} \end{bmatrix}\]
3. Design of Controllers
A. TID Controller
TID controllers exhibit similarities to PID controllers as they both incorporate A tilting component with a transfer function of S<sup>^</sup> (1/n) will be employed as the substitute for the proportional component of the controller. Figure 2 depicts the block diagram of the TID controller.
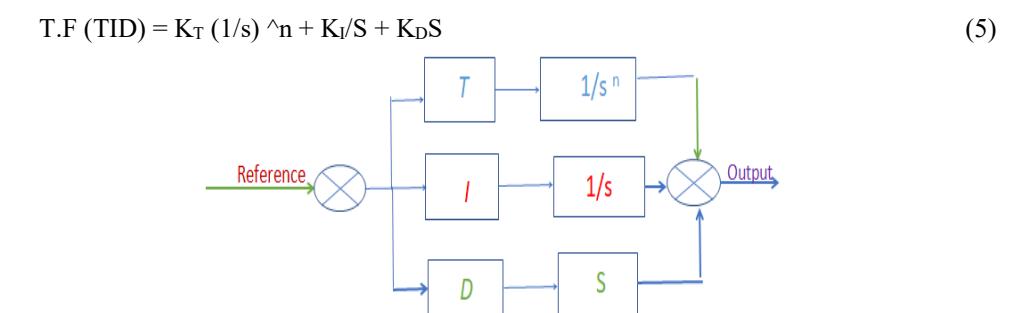
Figure 2. TID controller Block diagram
The TID controller surpasses a standard PID controller in terms of robustness, stability, flexibility, noise rejection, and adaptability. The TID controller offers significant advantages in certain applications, especially when dealing with complex system dynamics or when conventional PID control fails to meet performance criteria. Nevertheless, the efficacy of a TID controller is contingent upon the particular system and necessitates meticulous calibration and design[28-30].
A TID controller is particularly advantageous over a PID controller in systems where dead time is a significant factor. Its ability to handle delays directly, simplify tuning, and maintain stability in delayed systems makes it a preferred choice in such scenarios. However, for many other types of systems, especially those without significant time delays, a PID controller remains a versatile and widely used solution.
The gains are assigned within the maximum and minimum bounds, and the appropriate scaling parameter values are determined to limit or reduce the overall error function throughout the specified period. When constructing a modern controller using a heuristic optimisation approach, the objective function is first built with an emphasis on the suitable constraints and criteria. The objective function employed to enhance the effectuation of the suggested controller is the integral square error (ISE) criteria[31].
\[J = \int_{0}^{t_{stin}} ((\Delta f_1)^2 + (\Delta f_2)^2 + (\Delta p_{tie})^2) dt\] (6)
Hence, the optimization issue can be formulated as the minimization of variable J, as depicted in equation 6. \(K_{min} \le K \le K_{max}\). The range of values for n is between -2 and 2, with a minimum value of -2 and a maximum value of 2.
4. Cuttlefish Optimization Algorithm
The traditional Cuttlefish optimization method has been employed to optimize the process of extracting features, as explained in detail in this document. The COA method [32] is utilized as a search approach to determine the most exemplary subset of features. As depicted in Figure 3, the program replicates the physiological mechanisms by which cuttlefish modify their coloration. The observed patterns and hues in cuttlefish can be attributed to the phenomenon of light reflection from several layers of cells, namely chromatophores, leucophores, and iridophores. The analysis of the CFA focuses on two main processes: visibility and reflection. This study uses the reflection process to imitate the light reflection mechanism, while the visibility function is utilized to model the visibility of associated patterns.
Figure 3. Cuttlefish Optimization Algorithm
Procedure for implementing the Cuttlefish Algorithm (CFA):
- The conventional cuttlefish algorithm:
Cuttlefish are marine creatures that are classified as molluscs. They possess an extraordinary ability to alter the colour and patterns of their skin in reaction to their environment. The interaction between chromatophores, leucophores, and iridophores within cells enables this result. By blending with the reflected light, these cells produce various colours and patterns.
- Initialization:
The technique utilizes a population of initial solutions composed of a subset of selected data points and a subset of unselected data points. When the subset of data points that were not picked is divided by the subset that was chosen, the resulting value should be zero. Each decision tree classifier calculates the fitness value for a selected subset of points in each pi of the subset. It is advisable to retain the subset of points that demonstrate a superior fitness value as both the optimal subset and the optimal subset of points. The optimal selection of data points should have a smaller dimension than the Avbest subset. Every starting solution is linked to an unselected subset of points and a selected subset of points. The goal is to determine the fitness value associated with each one initial solution of data values. An optimal arrangement of data points is used to develop and maintain the ideal arrangement of data points.
- Feature selection:
In the recent past, there has been a notable surge in the amount of data, resulting in the integration of a wide range of characteristics and attributes. As a result, the time it takes to perform the computation has been prolonged, resulting in the wastage of computational
resources, as most of these factors do not have any impact on the conclusion of a predictive model. Hence, it is customary to choose a subset of characteristics by considering the relative relevance of each variable, as shown by their separate weights, which have a more substantial influence on accurately forecasting the outcome. All other attributes are disregarded. CFA utilizes two unique processes, namely reflection and visibility, to identify a new and innovative solution. These examples perform a thorough search by using the significance of each point to determine a new area that encompasses the best solution within a specific range. Figure 4 displays the flowchart of the cuttlefish algorithm.
The methodology for determining the new solution (new P) by the use of reflection and visibility is outlined as follows.
The equation can be expressed as P = reflection + visibility.
The equation is i = R*G1(i).
The visibility of points j is equal to \(V^*\) (Best points (j) – G1 (i). points (j)
Where, G1 refers to a collection of cells. The variable R represents the measure of reflection.
The variable V represents the measure of visibility.
CFA Flow Chart:
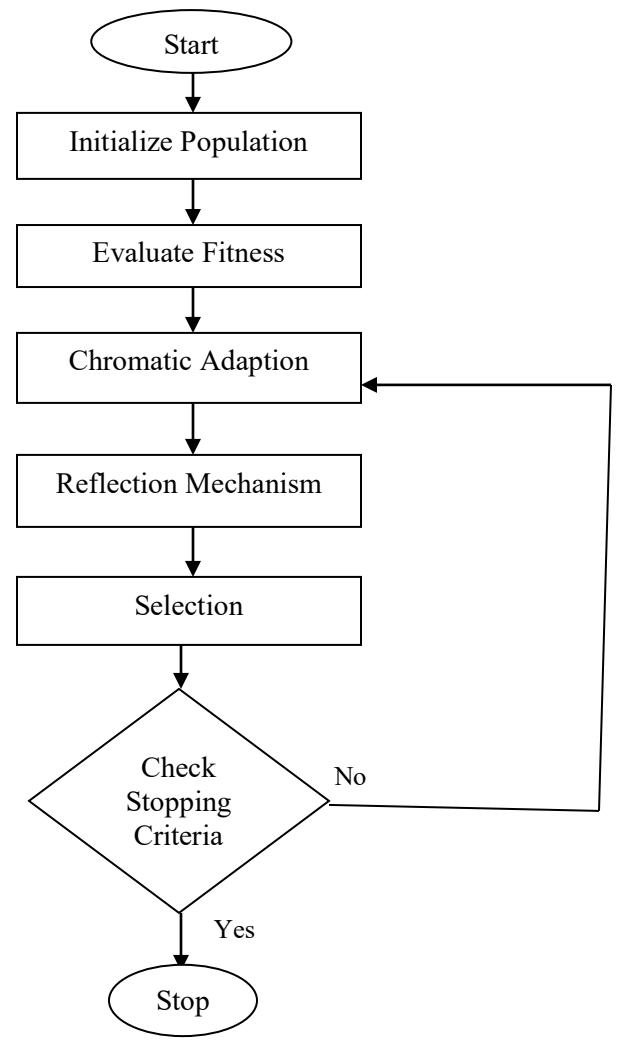
Figure 4. Flowchart of Cuttlefish Algorithm
Algorithm of the CFA:
Step : 1 Define the Objective Function:
The goal is to minimize error in frequency and tie-line power deviation. The objective function as shown in Equ(6) is to be minimized.
Step : 2 Generate Initial Population
The algorithm starts with a random population of controller parameters (e.g., Kt, Ki, Kd). As shown in Equ(5).
Step : 3 Evaluate Fitness
Simulate the power system with those parameters and compute frequency and tieline deviations. The fitness function measures how good the controller's performance is (less overshoot, faster settling time).
Step : 4 Update Solutions
Reflection explores nearby solutions.
Visibility lets the algorithm jump to new regions if stuck in local minima. Color changing adjusts the balance between exploration and exploitation.
Step : 5 Select the Best Parameters
The algorithm iterates until it finds the optimal controller settings that ensure: Fast frequency restoration, Minimum tie-line power oscillations and Robust performance under load changes.
5. Results and Discussion
Deregulation of the power system is an imperative requirement when assessing the most recent TID controller. In addition to linear components, nonlinear components GRC and GDB are assessed. Following this, a GRC threshold of 0.05 percent is enforced at some stage during the configuration procedure. GDB is more accurately defined as the replacement rate of the steam valve characteristic when torque is absent. A potential limitation of 0.06 percent arises when the GDB is incorporated.
Case 1: pool-co based transaction
A pool co-based transaction refers to the practice of redistributing the electricity load among power generation companies (GENCOs) in a certain region by distribution companies (DISCOs). The region's participation factor is established at 0.5 for an interval of four attributes that are deemed to be equivalent. Figures 5 (a), 5 (b), and 5 (c) illustrate the variations in frequency for area-1, area-2, and tie line power, respectively, while using various controllers based on COA and GWO. Table 1 illustrates that the performance of the COAbased controller is superior to that of the GWO-based controller when utilizing a pool co-based transaction.
\[\text{[rumus tidak dapat ditampilkan dengan baik — lihat PDF asli]}\]
Table 1. Comparison of distinct optimization controllers under case 1
| S. No | % PO (p.u) | % PU (p.u) | ST (Sec) | |||||||
| Δf1 | Δf2 | ΔPtie | Δf1 | Δf2 | ΔPtie | Δf1 | Δf2 | ΔPtie | ISE | |
| GWO-PID [21] | 0.005 | 0.004 | - | 0.058 | 0.062 | - | 5.6 | 5.4 | 5.4 | 0.076 |
| COA-PID [22] | 0.003 | 0.004 | - | 0.038 | 0.04 | - | 4.8 | 4.6 | 4.8 | 0.063 |
| GWO-TID [25] | 0.002 | 0.003 | - | 0.028 | 0.03 | - | 4.6 | 4.2 | 4.0 | 0.051 |
| COA-TID (proposed) | 0.001 | 0.003 | - | 0.022 | 0.028 | - | 4.2 | 3.8 | 3.7 | 0.038 |
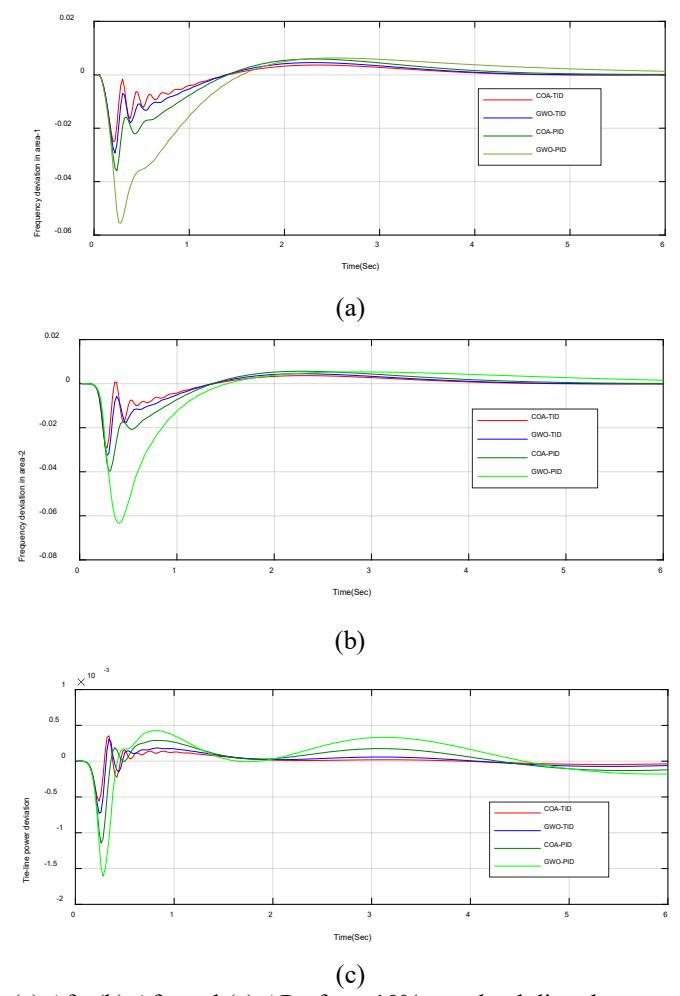
Figure 5. (a) Δf1, (b) Δf2, and (c) ΔPtie for a 10% step load disturbance under case 1
Case 2: Bilateral-based transaction
A bilateral based transaction refers to the sharing of the load between DISCOs and GENCOs in another area. Figures 6 (a), 6 (b), and 6 (c) depict the fluctuations in frequency in area-1, area-2, and tie line power, respectively. Table 2 illustrates that the COA-based controller exhibits superior performance compared to the GWO-based controller in bilateral transactions.
Table 2. Comparison of distinct optimization controllers under case 2.
| S. No | % PO (p.u) | % PU (p.u) | ST (Sec) | ISE | ||||||
| Δf1 | Δf2 | ΔPtie | Δf1 | Δf2 | ΔPtie | Δf1 | Δf2 | ΔPtie | ||
| GWO-PID [21] | 0.01 | 0.003 | - | 0.07 | 0.08 | 0.035 | 5.6 | 4.8 | 5.2 | 0.056 |
| COA-PID [22] | 0.008 | 0.003 | - | 0.065 | 0.06 | 0.033 | 5.2 | 4.6 | 4.8 | 0.043 |
| GWO-TID [25] | 0.007 | 0.002 | - | 0.063 | 0.05 | 0.032 | 4.8 | 4.2 | 4.6 | 0.031 |
| COA-TID (proposed) | 0.005 | 0.002 | - | 0.06 | 0.03 | 0.03 | 4.6 | 3.8 | 4.2 | 0.026 |
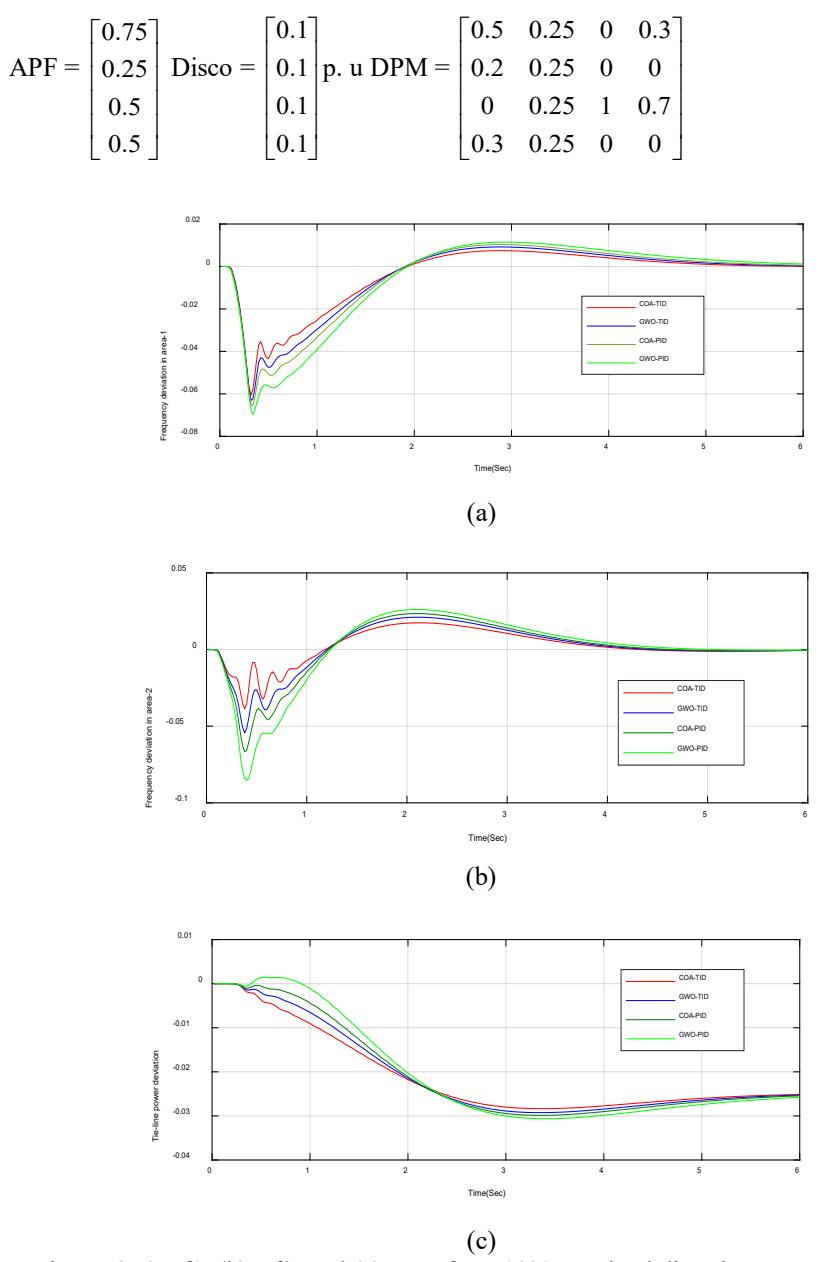
Figure 6. a) \(\Delta f1\), (b) \(\Delta f2\), and (c) \(\Delta P_{tie}\) for a 10% step load disturbance under case 2.
Case 3: Contract violation
In this case, there is a violation of the contract as there is a request for excessive power above what is provided explicitly in the contract. Considering Case 2 once again, with the adjustment that DISCO1 requires an additional 0.1 (p.u. MW) of power. Figures 7(a) and (b) show the frequency deviation in area-1 and area-2, respectively. The variation of tie-line power is illustrated in Figure 7 (c) when various controllers based on COA and GWO are employed. Based on the results shown in Table 3, it can be observed that the COA-based controller exhibits superior performance in transactions pertaining to contract violations compared to the GWO-based controller.
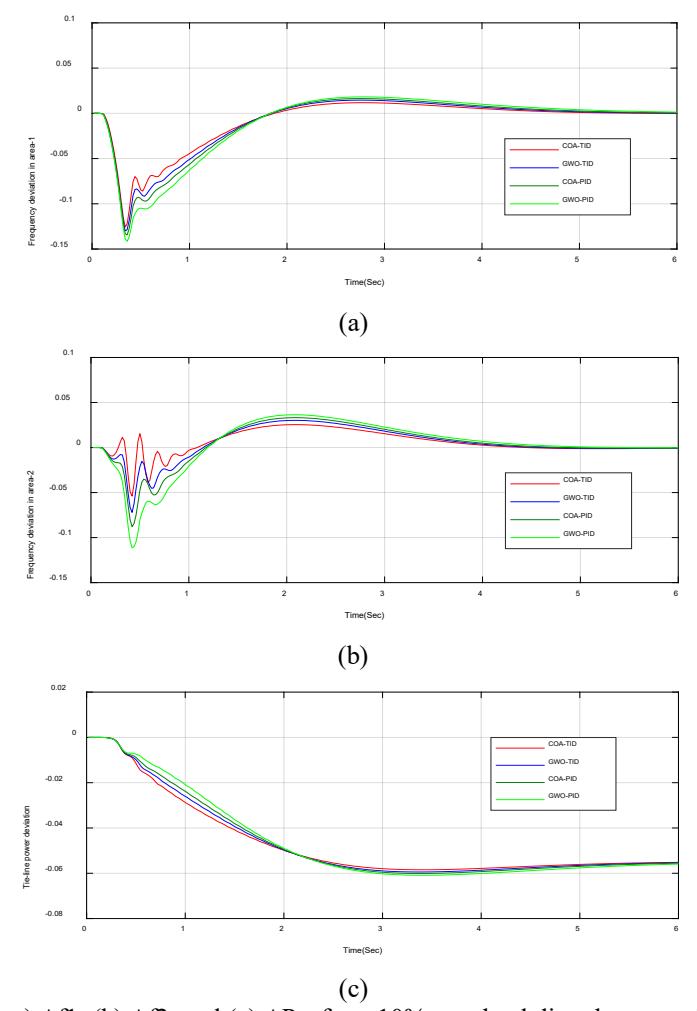
Figure 7. a) Δf1, (b) Δf2, and (c) ΔPtie for a 10% step load disturbance under case 3
Table 3. Comparison of distinct optimization controllers under case 3
| S. No | % PO (p.u) | % PU (p.u) | ST (Sec) | |||||||
|---|---|---|---|---|---|---|---|---|---|---|
| Δf1 | Δf2 | ΔPtie | Δf1 | Δf2 | ΔPtie | Δf1 | Δf2 | ΔPtie | ISE | |
| GWO-PID [21] | 0.025 | 0.04 | - | 0.14 | 0.12 | 0.062 | 5.4 | 4.6 | 5.8 | 0.198 |
| COA-PID [22] | 0.024 | 0.03 | - | 0.13 | 0.08 | 0.060 | 4.8 | 4.4 | 5.4 | 0.136 |
| GWO-TID [25] | 0.022 | 0.02 | - | 0.12 | 0.06 | 0.058 | 4.6 | 4.2 | 5.2 | 0.111 |
| COA-TID | ||||||||||
| (proposed) | 0.020 | 0.01 | - | 0.12 | 0.05 | 0.056 | 4.4 | 3.9 | 4.8 | 0.096 |
6. Conclusion
This study evaluates the effectiveness of the Tilt Integral Derivative (TID) controller in an open-market power system under different power transaction scenarios. The Cuttlefish Optimization Algorithm (COA) was employed to fine-tune the TID controller's parameters, and its performance was compared against the Grey Wolf Optimization (GWO) algorithm. Simulation results demonstrate that COA-tuned controllers consistently outperform GWOtuned controllers, particularly in terms of faster settling times, reduced peak overshoot, and minimized peak undershoot across various loading conditions. Overall, the findings confirm that the COA-optimized TID controller provides superior frequency regulation compared to GWO-based tuning methods.
7. References
- [1]. Kumar, Sambugari Anil, M. Siva Sathya Narayana, and K. Jithendra Gowd. "Load frequency control of thermal system under deregulated environment using slime mould algorithm." International Journal of Power Electronics and Drive Systems 12, no. 4 (2021): 2221-2229.
- [2]. Abraham, Rajesh Joseph, D. Das, and Amit Patra. "Load following in a bilateral market with local controllers." International Journal of Electrical Power & Energy Systems 33, no. 10 (2011): 1648-1657.
- [3]. Hossaiin, M. F., T. Takahashi, M. G. Rabbani, M. R. I. Sheikh, and M. S. Anower. "Fuzzy-proportional integral controller for an AGC in a single area power system." In 2006 International Conference on Electrical and Computer Engineering, pp. 120-123. IEEE, 2006.
- [4]. Das, Kallol, Priyanath Das, and Sharmistha Sharma. "Load frequency control using classical controller in an isolated single area and two area reheat thermal power system." International Journal of Emerging Technology and Advanced Engineering 2, no. 3 (2012): 403-409.
- [5]. Saxena, Sahaj, and Yogesh V. Hote. "Load frequency control in power systems via internal model control scheme and model-order reduction." IEEE transactions on power systems 28, no. 3 (2013): 2749-2757.
- [6]. K.P. S. Parmar, S. Majhi, and D. P. Kothari, "LFC of an interconnected power system with multi-source power generation in deregulated power environment," Int. J. Elect. Power Energy Syst., vol. 57, pp. 277-286, May 2014, doi: 10.1016/j.ijepes.2013.11.058.
- [7]. Sambugari Anil Kumar, M. Siva Sathya Narayana, K. Jithendra Gowd, "Load Frequency Control of Multi area system under deregulated environment using Artificial Gorilla Troops Optimization (AGTO)", Bulletin of Electrical Engineering and Informatics, Vol. 11, No. 6, December 2022.
- [8]. Magdy G, Mohamed EA, Shabib G, Elbaset AA, Mitani Y. "SMES based a new PID controller for frequency stability of a real hybrid power system considering high wind power penetration," IET Renew Power Gener 2018;12(11):1304–13. https:// doi.org/10.1049/rpg2.v12.1110.1049/iet-rpg.2018.5096.
- [9]. G.T. Chandra Sekhar, R. K. Sahu, A. K. Baliarsingh, and Sidhartha Panda, "Load frequency control of power system under deregulated environment using optimal firefly algorithm," Int. J. Electr. Power Energy Syst., vol.74, pp.195–211, 2016, doi: 10.1016/j.ijepes.2015.07.025.
- [10]. L. C. Saikia, J. Nanda, and S. Mishra, "Performance comparison of several classical controllers in AGC for multi-area interconnected thermal system,"International Journal of Electrical Power & Energy Systems, vol.33, no. 3, pp.394-401, March 2011, doi: 10.1016/j.ijepes.2010.08.036.
- [11]. B.K. Sahu, T. K. Pati, J. R. Nayak, S. Panda, and S. K. Kar, "A novel hybrid LUS-TLBO optimized fuzzy-PID controller for load frequency control of multi-source power system," Int. J. Electr. Power Energy Syst., vol.74, pp. 58-69, January 2016, doi: 10.1016/j.ijepes.2015.07.020.
- [12]. A. Huddar and P. S. Kulkarni, "A robust method of tuning a decentralized proportionalintegral load frequency controller in a deregulated environment using genetic algorithms," Electric Power Components and Systems,vol. 37, no. 3, pp. 265-286, February 2009, doi: 10.1080/15325000802454419.
- [13]. Md N. Anwar and S. Pan, "A new PID load frequency controller design method in frequency domain through direct synthesis approach,"Int. J. Elect. Power Energy Syst., vol. 67, pp. 560- 569, May 2015, doi: 10.1016/j.ijepes.2014.12.024.
- [14]. S. Rupatharani and S. Selvakumari, "Load Frequency Control of Multi-Area Power Systems using Genetic Algorithm," International Journal of Engineering Research & Technology ,vol. 3, no. 16, 2015.
- [15]. Sönmez, Sahin, and Saffet Ayasun. "Stability region in the parameter space of PI controller for a single-area load frequency control system with time delay." IEEE Transactions on Power Systems 31.1 (2015): 829-830.
- [16]. Chandrakala, KRM Vijaya, S. Balamurugan, and K. Sankaranarayanan. "Variable structure fuzzy gain scheduling based load frequency controller for multi source multi area hydro thermal system." International Journal of Electrical Power & Energy Systems 53 (2013): 375-381.
- [17]. Çam, Ertuğrul, and Ilhan Kocaarslan. "A fuzzy gain scheduling PI controller application for an interconnected electrical power system." Electric Power Systems Research 73.3 (2005): 267-274.
- [18]. H. Haes Alhelou, M. E. Hamedani Golshan, and M. Hajiakbari Fini, "Wind Driven Optimization Algorithm Application to Load Frequency Control in Interconnected Power Systems Considering GRC and GDB Nonlinearities," Electric Power Components and Systems, vol. 46, no. 11–12, pp. 1223–1238, Jul. 2018, https://doi.org/10.1080/15325008. 2018.1488895.
- [19]. Velusami, S., and I. A. Chidambaram. "Decentralized biased dual mode controllers for load frequency control of interconnected power systems considering GDB and GRC nonlinearities." Energy Conversion and Management 48, no. 5 (2007): 1691-1702.
- [20]. Jagatheesan, Kaliannan, B. Anand, Sourav Samanta, Nilanjan Dey, Amira S. Ashour, and Valentina E. Balas. "Design of a proportional-integral-derivative controller for an automatic generation control of multi-area power thermal systems using firefly algorithm." IEEE/CAA Journal of Automatica Sinica 6, no. 2 (2017): 503-515.
- [21]. [21] Paliwal, Nikhil, Laxmi Srivastava, and Manjaree Pandit. "Application of grey wolf optimization algorithm for load frequency control in multi-source single area power system." Evolutionary Intelligence (2022): 1-22.
- [22]. [22] M. Khatri and A. Kumar, "Stability Inspection of Isolated Hydro Power Plant with
- [23]. Cuttlefish Algorithm," 2020 International Conference on Decision Aid Sciences and Application (DASA), Sakheer, Bahrain, 2020, pp. 459-463, doi: 10.1109/DASA51403.2020.9317242.
- [24]. Seekuka, Jitsaran, Rapeepong Rattanawaorahirunkul, Siriporn Sansri, Sawinee
- [25]. Sangsuriyan, and Aran Prakonsant. "AGC using Particle Swarm Optimization based PID
- [26]. controller design for two area power system." In 2016 International Computer Science and Engineering Conference (ICSEC), pp. 1-4. IEEE, 2016.
- [27]. Nayak, Pratap Chandra, Umesh Chandra Prusty, Ramesh Chandra Prusty, and Ajit Kumar
- [28]. Barisal. "Application of SOS in fuzzy based PID controller for AGC of multi-area power
- [29]. system." In 2018 Technologies for Smart-City Energy Security and Power (ICSESP), pp.
- [30]. 1-6. IEEE, 2018.
- [31]. Kumar, Sambugari Anil, Mungara Siva Sathya Narayana, and Kambali Jithendra Gowd.
- [32]. "Application of a TID Controller for the LFC of a Multi Area System using HGS Algorithm." Engineering, Technology & Applied Science Research 13, no. 3 (2023):
- [33]. 10691-10697.
- [34]. Kumar, Nagendra, Suman Lata, Akhilesh Singh, Sachit Rathee, and Pardeep Sangwan. "Load Frequency Control in Multiarea Power System Using TID Control Scheme." In Cyber Technologies and Emerging Sciences: ICCTES 2021, pp. 457-470. Singapore: Springer Nature Singapore, 2022.
- [35]. Topno, Pretty Neelam, and Saurabh Chanana. "Automatic generation control using optimally tuned tilt integral derivative controller." In 2016 IEEE First International Conference on Control, Measurement and Instrumentation (CMI), pp. 206-210. IEEE, 2016.
- [36]. Sharma, Chetan, Manoj Kumar Kar, Harsh Goud, and Prasad V. Joshi. "Frequency Regulation of Power System using TID Controller." In 2024 8th International Conference on Computing, Communication, Control and Automation (ICCUBEA), pp. 1-4. IEEE, 2024.
- [37]. Ahmad, Rafeque, Ibraheem, Yogendra Arya, and Mohammad Faraz Ahmer. "LFC of Single-Area Multisource Power Systems Employing SSA-Based TID Controller." In International Conference on Electric Power and Renewable Energy, pp. 331-345. Singapore: Springer Nature Singapore, 2024.
- [38]. Behera, Sarada Prasanna, Ashutosh Biswal, Binodinee Swain, and Sidhartha Sankar Samantray. "Hybrid power systems Frequency regulation using TID based robust controller design and differential evolution (DE) algorithm." In 2018 Technologies for Smart-City Energy Security and Power (ICSESP), pp. 1-6. IEEE, 2018.
- [39]. Kumar, Sambugari Anil, M. S. S. Narayana, and K. Jithendra Gowd. "Two area LFC of thermal system under open market scenario using Hunger Games Search Algorithm." International Journal of Special Education 37, no. 3 (2022): 4098-4109.
- [40]. Eesa, Adel Sabry, and Zeynep Orman. "A new clustering method based on the bio‐inspired cuttlefish optimization algorithm." Expert Systems 37, no. 2 (2020): e12478.
Haritha Guddeti received Bachelor degree in Electrical Engineering from JNTU Anantapur in 2009. She received the Master degree in Power Electronics And Electric Drives from JNTUA, Anantapur in 2012. Currently she is Research Scholar in Electrical Engineering department, Dr. M.G.R. Educational and Research Institute, Deemed to be University, Chennai, India.She is presently working as Assistant Professor in G.Pulla Reddy Engineering College(Autonomous) Kurnool , published 7 international Journals and 3 International conferences. Her research interests include Power systems and Renewable Energy sources.She can be contacted at email: gharitha804@gmail.com.
Kannan A. is the Associate Professor in Department of Electrical and Electronics Engineering of Dr. M.G.R. Educational and Research Institute, Deemed to be University, Chennai, since July 2005. He obtained B.E. degree in Electrical and Electronics Engineering from Mepco Schlenk Engineering College, Sivakasi, M.Tech. degree in Applied Electronics and Ph.D. in the area of Power Quality from Dr. M.G.R. Educational and Research Institute, Deemed to be University, Chennai. He has Two decades of teaching and research experience in India. His experiences include teaching at Jaya Engineering College, Chennai and Srivenkateshwara College of Engineering and Technology, Tirupachre, Tiruvallure. He is a recognized
Research Supervisor of Dr. M.G.R. Educational and Research Institute, Deemed to be University for Ph.D. and M.S. (by research). He can be contacted at email: kannan.eee@drmgrdu.ac.in.