Kiet Tran-Trung1 and Phu-Nguyen Le2
1 Faculty of Computer Science, Ho Chi Minh City Open University, Ho Chi Minh 722000, Vietnam 2 Faculty of Engineering and Technology, Nguyen Tat Thanh University, Vietnam kiet.tt@ou.edu.vn, lpnguyen@ntt.edu.vn
Abstract: Industrial robotic manipulators are importance in the industrial. However, they are low accuracy due to the deviation of the mathematical model and the actual manipulator. Moreover, the robot manipulators are not ideal static mechanism. The joints and links of the robots are bended when a payload is applied. To recognize the kinematic and compliance parameters of the robot manipulator, this study proposed a method to identify these constrains at the same time using the culture algorithm and kinematic calibration. The method could be process in two phases. The kinematic parameters of the robot are identified in the first phase using the conventional kinematic calibration. In the second phase, the culture algorithm is employed for determining the compliance constrains. The two phases are applied repeatedly until convergence. The suggested algorithm is quick converge, it also gives the knowledge of errors, and enhance the accuracy of the robot. The effectiveness of the proposed method is demonstrated by experiment on a YS100 robot, comparing it to conventional kinematic calibration and the process using genetic algorithm to identify stiffness parameters, thereby clarifying the advantage of the proposed method.
Keywords: automation; culture algorithm; robotic manipulator; robotic calibration;
1. Introduction
In order to enhance the efficiency of industrial production and decrease possible losses of unqualified items, the role of robotic manipulators is becoming important. The robotic manipulator is one of the most important chains in the industry, as its reliability is crucial for the production process. Since robot manipulators are famous for high repeatability and low accuracy, there is a requirement to enhance the precision of the robot manipulator. The low accuracy property of the robot is caused by the difference in the mathematical model which is used to describe the robot from the actual robot manipulator. There are two methods to solve the inaccuracy problem of the robots. The first one is to build a robot that has every parameter as close to the nominal values as possible. The second method is to find out a correct mathematical model to describe the actual robot. This method is named robotic calibration. Numerous calibration methods have been proposed by researchers throughout the decades[1], [2], [11], [12], [3]–[10]]. Generally, they could be classified into two main streams: geometric calibration and non-geometric calibration.
The purpose of the geometric calibration is to find out the correctly model to describe the geometric parameters of the robot manipulators. For many decades, the conventional Denavit-Hartenberg (D-H) model[3]–[5] is one of the most famous geometric calibration methods for the benefits of concisely describe a robot. The method is still employed in the recent day with modifications[13]–[15]. However, the use of the traditional D-H technique has a major drawback: when consecutive joint axes are parallel, the parameters are no longer unique unless additional rules are added. A small deviation in the measurements might produce a considerable change in the parameters, hence different parameterizations, such as the zero-reference position approach, are sometimes utilized. Gupta et al. proposed the zero-reference position method[8]. Zhuang et al. [7], [16] proposed the CPC model, while Okamura et al. suggested the POE model[9–11,17. These methods have been extensively studied throughout the years. However,
Received: December 10th, 2024. Accepted: June 30th, 2025
DOI: 10.15676/ijeei.2025.17.2.9
the methods have similar disadvantages for nongeometric errors, since these sources of errors are not taken into account.
Researchers showed that the sources of robotic manipulator errors are also come from nongeometric sources especially the link and joint compliances [1-4]. There are attempts to model the link and joint compliances by Chen et al. [11-12] The optimization methods are also applied for determining the optimum postures that offer the best nongeometric error compensators [13-14]. The neural networks are also employed to identify the compliance parameters [15-16]. However, the methods do not supply the sources of errors correctly.
In 1994, Reynolds proposed an optimization method named the cultural algorithm (CA)[17] to replicate social development. The CA comprises of an evolving population of agents whose experiences are incorporated into a belief space made up of numerous types of symbolic knowledge. In the CA progression, five general forms of knowledge that reflect generic information found in cultural systems were eventually added to the cultural space. The knowledge sources include normative, spatial (topographic), temporal (historic), domain, and exemplar knowledge. The CA framework is well-suited to enabling a variety of learning activities, including ensemble learning. The numerous information sources in the belief space may be regarded as an ensemble of classifiers, with the acceptance function gathering sample data from the agent population using techniques such as bagging and boosting. The influence function indicates the ensemble's effect on agent activities. The CA has been effectively implemented in a variety of application areas[18][19][20].
In this paper, a new industrial robot calibration approach is developed that uses a kinematic calibration (KM) and the Culture Algorithm (CA). This method identifies the kinematic and stiffness parameters at the same time. The enhanced position accuracy and correctness identified kinematic and stiffness parameters of the proposed method over conventional calibration method firmly confirms the effectiveness and feasibility of the methods.
2. Identification Of Joint Compliance by CA and Kinematic Parameters
The joint bends of N DOF robot is expressed as
\[\Delta\theta_c = \tau X \tag{1}\]
In this equation, \(\Delta\theta_c\) is a N×1 joint deflection vector, The diagonal matrix \(\tau\) represents the effective torque in the robot joints at the static equilibrium position[12].
The position vector \(P_{real}\) of the tip of manipulator could be express by the following equation:
\[P_{real} = P_{kin} + \Delta P_{kin} + \Delta P_c \tag{2}\]
where \(P_{kin}\) is the tip's position as determined by the nominal kinematic parameters, \(\Delta P_{kin}\) is the positional errors due to the kinematic parameter errors, \(\Delta P_c\) is the positional errors due to the deflection of joints.
The CA is used in this study to determine the compliance properties of the joints. As a result, joint deflection may be determined. Simultaneously, a KM is performed to determine the robot's kinematic characteristics. The proposed method named SKCM-C by CA is characterized as follows.
Using the nominal geometric and compliance parameter for m solution \(X_k\) of the population, the positional error vector \(\Delta P_{i,k}\) is given:
\[\Delta P_{j,k} = P_{m_{i,k}} - P_{comp_{i,k}} \tag{3}\]
where \(P_{m_{i,k}}\) is the measuring and \(P_{comp_{i,k}}\) is the computing position. By applying least squares method, the kinematic errors could be identified:
\[\Delta \phi = [(J^T J)^{-1} J^T] \Delta P_{i,k} \tag{4}\]
where \(\Delta \phi = [\Delta \alpha \Delta \alpha \Delta \beta \Delta b \Delta d \Delta \theta]^T\) is the kinematic errors vector, and J is the Jacobian matrix that represents the kinematic errors to the positional errors of the robot.
The Eq.4 is applied repeatedly until the system reaching the convergence condition or maximum iteration. By applying the CA, assuming that the population is N=20, d=4 represents
the dimensions of stiffness vector \(C_k\), location of the \(i_{th}\) at \(i_{th}\) iteration is a \(X_{i(t)} = (X_{1i}, X_{2i}, ..., X_{di})\). i = 1, 2, 3, ..., N.
In this equation, \(\Delta\theta_c\) is a N×1 joint deflection vector, The diagonal matrix \(\tau\) represents the effective torque in the robot joints at the static equilibrium position[12].
By applying the CA, assuming that the population is N=20, d=4 represents the dimensions of stiffness vector \(C_k\), location of the \(i_{th}\) individual at \(i_{th}\) iteration is a \(X_{i(t)}=(X_{1i},X_{2i},...,X_{di})\). i=1,2,3...,N. In the beginning, the optimal position \(X_t^*\).
The pseudo-code of a cultural algorithm is shown as follows:
Generate the initial population
Initialize the belief space
Evaluate the initial population
Repeat
Update the belief space (with the individuals accepted)
Apply the variation operators (under the influence of the belief space)
Evaluate each child
Perform selection
While the end condition is not satisfied
The CA algorithm could be illustrated by the following figure:
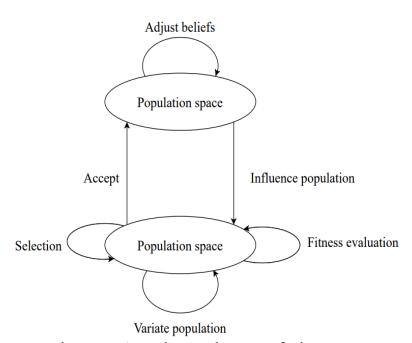
Figure 1. Flowchart of the CA
Overall, the process of the proposed method is showed in the figure 2
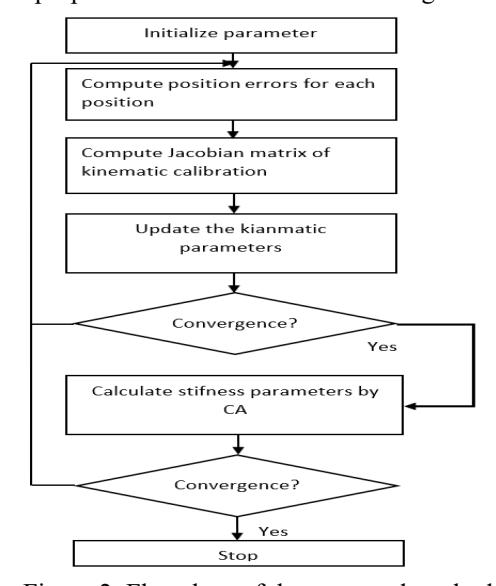
Figure 2. Flowchart of the proposed method
3. Experimental results
The proposed method (SKCM-C by CA) is applied to conduct on an industrial serial 6 degrees of freedom robot (Hyundai YS100 in Fig.3) to validate the efficacy of the proposed algorithm. Besides, the results of the calibration procedure are confirmed by the validation process with non-calibrated robot poses. Additionally, the result of traditional KM and the SKCM-C by CA algorithm are contrasted to show the capabilities of the proposed method.
Figure 3. Sketch of the YS100 robot
| ıi-1 (deg) | \(a_{i-1}(m)\) | \(\beta_{i-1}(deg)\) | \(b_i(m)\) | \(d_i(m)\) | \(\theta_i(deg)\) |
|---|---|---|---|---|---|
| 0.1 | -0.5 | 0.1 | 0.05 | 0.5 | 0.2 |
| 90.2 | 0.33 | - | - | 0 | 0.1 |
| -0.1 | 0.86 | 0.01 | - | -0.001 | -1 |
| 89.9 | 0.21 | - | - | 1.02 | -1.3 |
| -90.2 | 0.002 | - | - | 0.002 | -1.2 |
0.05
0.185
0.45
0
_
Table 1. Nominal parameters of the YS100 robot.
A. Experimental calibration results.
90.1
0.003
-0.3
\(\alpha_{i}\)
6
The data utilized in this experiment were obtained from the Advance Robot Manipulation Research Center at Ulsan University. The calibration is carried out using a YS100 robot with a payload of 110 kg, an API laser tracker[12].
_
These measurements are randomly classified into two groups Q1 and Q2. In the parameter identification process, the set Q1 including 25 robot configurations (Q1) is used.
Initially, the population of population is N=20, d=4 represents the dimensions of stiffness vector \(X_k\). The kinematic and joint compliance characteristics are found using the SKCM-C by CA technique, which is thoroughly discussed in section 2. Tables 2 and 3 show 25 kinematic parameters and 4 stiffness parameters of the manipulator after the calibration process. Using the process described in section 2, with GA replacing CA (GA-SKCM), the stiffness parameters are also presented in the table 4.
Table 2. Identified parameters of the YS100 robot.
| i | αi-1 (deg) | ai-1(m) | β i-1(deg) | bi(m) | di(m) | θi(deg) |
|---|---|---|---|---|---|---|
| 1 | -0.1748 | -0.0163 | 0.5113 | 0.0489 | 0.4868 | 0.2340 |
| 2 | 90.0140 | 0.3198 | - | - | 0(X) | 1.4122 |
| 3 | -0.0160 | 0.8700 | 0.0132 | - | -0.0018 | -1.6557 |
| 4 | 89.9848 | 0.2004 | - | - | 1.0299 | -1.3602 |
| 5 | -90.0122 | 0.0001 | - | - | 0.0008 | -2.2655 |
| 6 | 90.065 | 0.0021 | - | - | 0.1850(X) | 0(X) |
| T | - | -0.2815 | - | 0.0484 | 0.4239 | - |
("-": not available, "X": un-identifiable)
Table 3. Identified stiffness parameters of the YS100 robot using CA
| X2 | X3 | X4 | X5 | |
|---|---|---|---|---|
| Stiffness | 1.73 *10^6 | 1.203*10^6 | 0.299 *10^6 | 0.5724*10^6 |
Table 4. Identified stiffness parameters of the YS100 robot using GA
| X2 | X3 | X4 | X5 | |
|---|---|---|---|---|
| Stiffness | 1.609 *10^6 | 1.397*10^6 | 0.325 *10^6 | 0.577*10^6 |
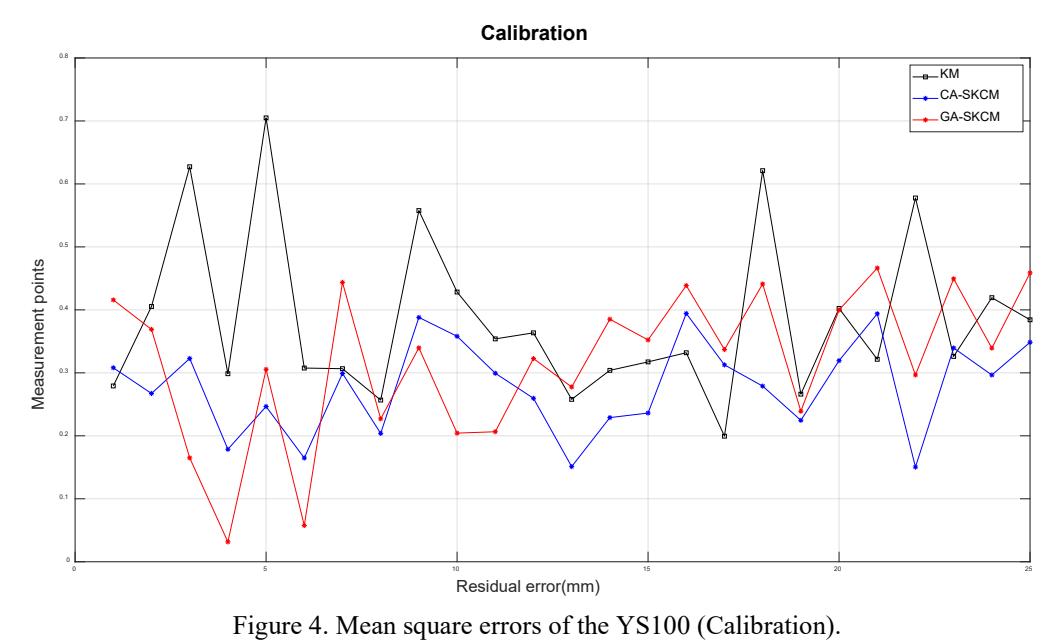
From the Fig.4, Table 4 and Table 5, it is easy to see that the proposed method had a better performance in contrasting to the traditional KM and GA-SKCM. The precision of the YS100 robot is increasing 91.17 % compare to the robot before calibration (mean errors from 3.39 mm to 0.28 mm), and 27.22% better than using KM (mean errors from 0.38 mm to 0.28 mm). It should be noted that the SKCM-C CA outperforms the SKCM-C GA in terms of maximum error, mean error, and deviation. The SKCM-C CA method also produces the lowest maximum errors.
| Mean(mm) | Max.(mm) | Std.(mm) | |||
| Nominal parameters | 3.3921 | 5.3390 | 1.0916 | ||
| Kinematic calibration | 0.3847 | 0.7048 | 0.1326 | ||
| SKCM-C GA | 0.318 | 0.4664 | 0.12 | ||
| SKCM-C CA | 0.28 | 0.39 | 0.0677 | ||
Table 5. Positional accuracy of the YS100 robot (Calibration).
B. Experimental validation results
Another robot configuration should be studied to prove the broad capabilities of the proposed method throughout the full robot workspace. The other set of 45 robot configurations (Q2) is chosen at random across the workspace to demonstrate the method's broad capabilities over the whole robot workspace. The steps for the KM technique, SKCM-C GA, and the suggested approach are carried out.
Table 6 and Fig. 5 illustrate the calibration results using the Q2 data set. From the Table 6 and Fig.5, it is easy to see that the proposed method had a better performance in contrasting to the traditional KM, and SKCM-C GA. The precision of the YS100 robot is increasing 98.13 % compare to the robot before calibration (mean errors from 12.27 mm to 0.23 mm), and 39.47% better than using KM (mean errors from 0.38 mm to 0.23 mm). The proposed method also produces the lowest maximum errors.
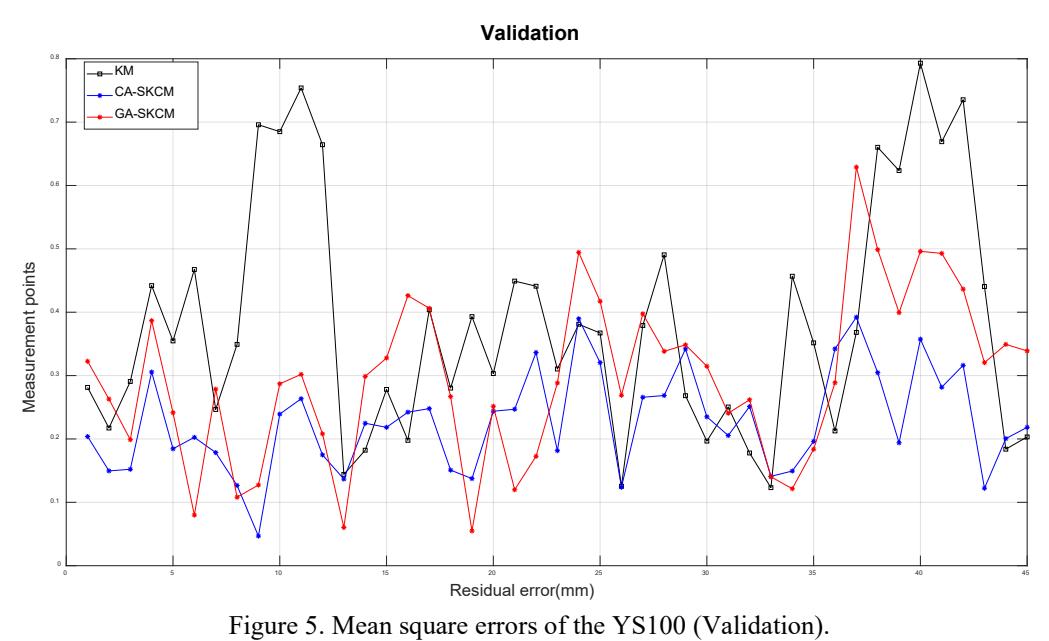
Table 6. Positional accuracy of the YS100 robot (Validation).
| Mean(mm) | Max.(mm) | Std.(mm) | |
|---|---|---|---|
| Nominal parameters | 12.2686 | 23.288 | 5.3057 |
| KM | 0.3842 | 0.793 | 0.1864 |
| SKCM-C GA | 0.2945 | 0.629 | 0.1299 |
| SKCM-C CA | 0.2255 | 0.3767 | 0.0765 |
4. Conclusions
The study proposed a novel calibration approach for industrial robot manipulators that simultaneously detects joint compliance and geometric parameters by integrating KM methodology with CA method. The suggested approach integrated geometric and non-geometric
calibration in order to improve the positioning precision of an industrial robotic manipulator. The suggested calibration process offers many benefits due to the integration of the two main methodologies, such as quick convergence, identify stiffness parameters of robot, and enhance the precision of the manipulator.
To show the efficacy and practicality of the suggested method, it is applied on the YS100 robot. The improved positional precision of the robot following calibration results shows the practicality and superiority of the technology over the KM. These advantages make the suggested solution more practical in a real-world offline programming environment.
5. Acknowledgment
The data utilized in this experiment were obtained from the Advance Robot Manipulation Research Center at Ulsan University.
We acknowledge Nguyen Tat Thanh University, Ho Chi Minh City, Vietnam for supporting this study.
6. References
- [1] C. Brisan and M. Hiller, "Aspects of calibration and control of PARTNER robots," in 2006 IEEE International Conference on Automation, Quality and Testing, Robotics, 2006, vol. 2, pp. 272–277.
- [2] R. Manne, "Analysis of two partial-least-squares algorithms for multivariate calibration," Chemom. Intell. Lab. Syst., vol. 2, no. 1–3, pp. 187–197, 1987.
- [3] J. C. John and others, "Introduction to robotics: mechanics and control," Read. Addison-Wesley, 1989.
- [4] S. Hayati and M. Mirmirani, "Improving the absolute positioning accuracy of robot manipulators," J. Robot. Syst., vol. 2, no. 4, pp. 397–413, 1985.
- [5] S. Hayati, K. Tso, and G. Roston, "Robot geometry calibration," in Proceedings. 1988 IEEE International Conference on Robotics and Automation, 1988, pp. 947–951.
- [6] K. C. Gupta, "Kinematic analysis of manipulators using the zero reference position description," Int. J. Rob. Res., vol. 5, no. 2, pp. 5–13, 1986.
- [7] H. Zhuang, Z. S. Roth, and F. Hamano, "A complete and parametrically continuous kinematic model for robot manipulators," in Proceedings., IEEE International Conference on Robotics and Automation, 1990, pp. 92–97.
- [8] H. Zhuang, L. K. Wang, and Z. S. Roth, "Error-model-based robot calibration using a modified CPC model," Robot. Comput. Integr. Manuf., vol. 10, no. 4, pp. 287–299, 1993.
- [9] K. Okamura and F. C. Park, "Kinematic calibration using the product of exponentials formula," Robotica, vol. 14, no. 4, pp. 415–421, 1996.
- [10] G. Chen, L. Kong, Q. Li, H. Wang, and Z. Lin, "Complete, minimal and continuous error models for the kinematic calibration of parallel manipulators based on POE formula," Mech. Mach. Theory, vol. 121, pp. 844–856, 2018.
- [11] G. Chen, H. Wang, and Z. Lin, "Determination of the identifiable parameters in robot calibration based on the POE formula," IEEE Trans. Robot., vol. 30, no. 5, pp. 1066–1077, 2014.
- [12] J. Zhou, H.-N. Nguyen, and H.-J. Kang, "Simultaneous identification of joint compliance and kinematic parameters of industrial robots," in International journal of precision engineering and manufacturing, 2014, vol. 15, no. 11, pp. 2257–2264.
- [13] C. Klug, D. Schmalstieg, T. Gloor, and C. Arth, "A complete workflow for automatic forward kinematics model extraction of robotic total stations using the Denavit-Hartenberg convention," J. Intell. Robot. Syst., vol. 95, no. 2, pp. 311–329, 2019.
- [14] C. Faria, J. L. Vilaça, S. Monteiro, W. Erlhagen, and E. Bicho, "Automatic Denavit-Hartenberg Parameter Identification for Serial Manipulators," in IECON 2019-45th Annual Conference of the IEEE Industrial Electronics Society, 2019, vol. 1, pp. 610–617.
- [15] C. A. Morar, M. H\uagan, I. Doroftei, and \cStefan Marinca, "Analog Matrix Multiplier Dedicated to the Denavit-Hartenberg Algorithm," in 2019 International Symposium on Signals, Circuits and Systems (ISSCS), 2019, pp. 1–4.
- [16] H. N. Nguyen, J. Zhou, and H. J. Kang, "A calibration method for enhancing robot accuracy through integration of an extended Kalman filter algorithm and an artificial neural network," Neurocomputing, vol. 151, no. P3, pp. 996–1005, 2015, doi: 10.1016/j.neucom.2014.03.085.
- [17] R. G. Reynolds, "An introduction to cultural algorithms," in Proceedings of the third annual conference on evolutionary programming, 1994, pp. 131–139.
- [18] C. A. C. Coello and R. L. Becerra, "Evolutionary multiobjective optimization using a cultural algorithm," in Proceedings of the 2003 IEEE Swarm Intelligence Symposium. SIS'03 (Cat. No. 03EX706), 2003, pp. 6–13.
- [19] C. A. Coello Coello and R. L. Becerra, "Efficient evolutionary optimization through the use of a cultural algorithm," Eng. Optim., vol. 36, no. 2, pp. 219–236, 2004.
- [20] X. Yuan and Y. Yuan, "Application of cultural algorithm to generation scheduling of hydrothermal systems," Energy Convers. Manag., vol. 47, no. 15–16, pp. 2192–2201, 2006.
Kiet Tran-Trung received the master's degree from Ho Chi Minh City Pedagogical University, Vietnam. He is currently a Lecturer with Ho Chi Minh City Open University. His research interests include machine learning and computer vision, and meta heuristic optimization applications.
Phu-Nguyen Le received a B.S. degree in electrical engineering from Da Nang University of Technology, Da Nang, Vietnam, in 2012. He received his Ph.D. degree in the School of Electrical Engineering, University of Ulsan, Ulsan, South Korea in 2021. He is currently a lecturer in Faculty of Engineering and Technology, Nguyen Tat Thanh University. His research interests include sensor-based robotic applications, robot calibration, and artificial intelligent-based robotic calibration.